
SeaWatch is a conceptual command-and-control experience for operators supervising autonomous maritime vehicles. This case study focuses on one critical workflow: helping an operator respond when a vessel unexpectedly deviates from its planned route.

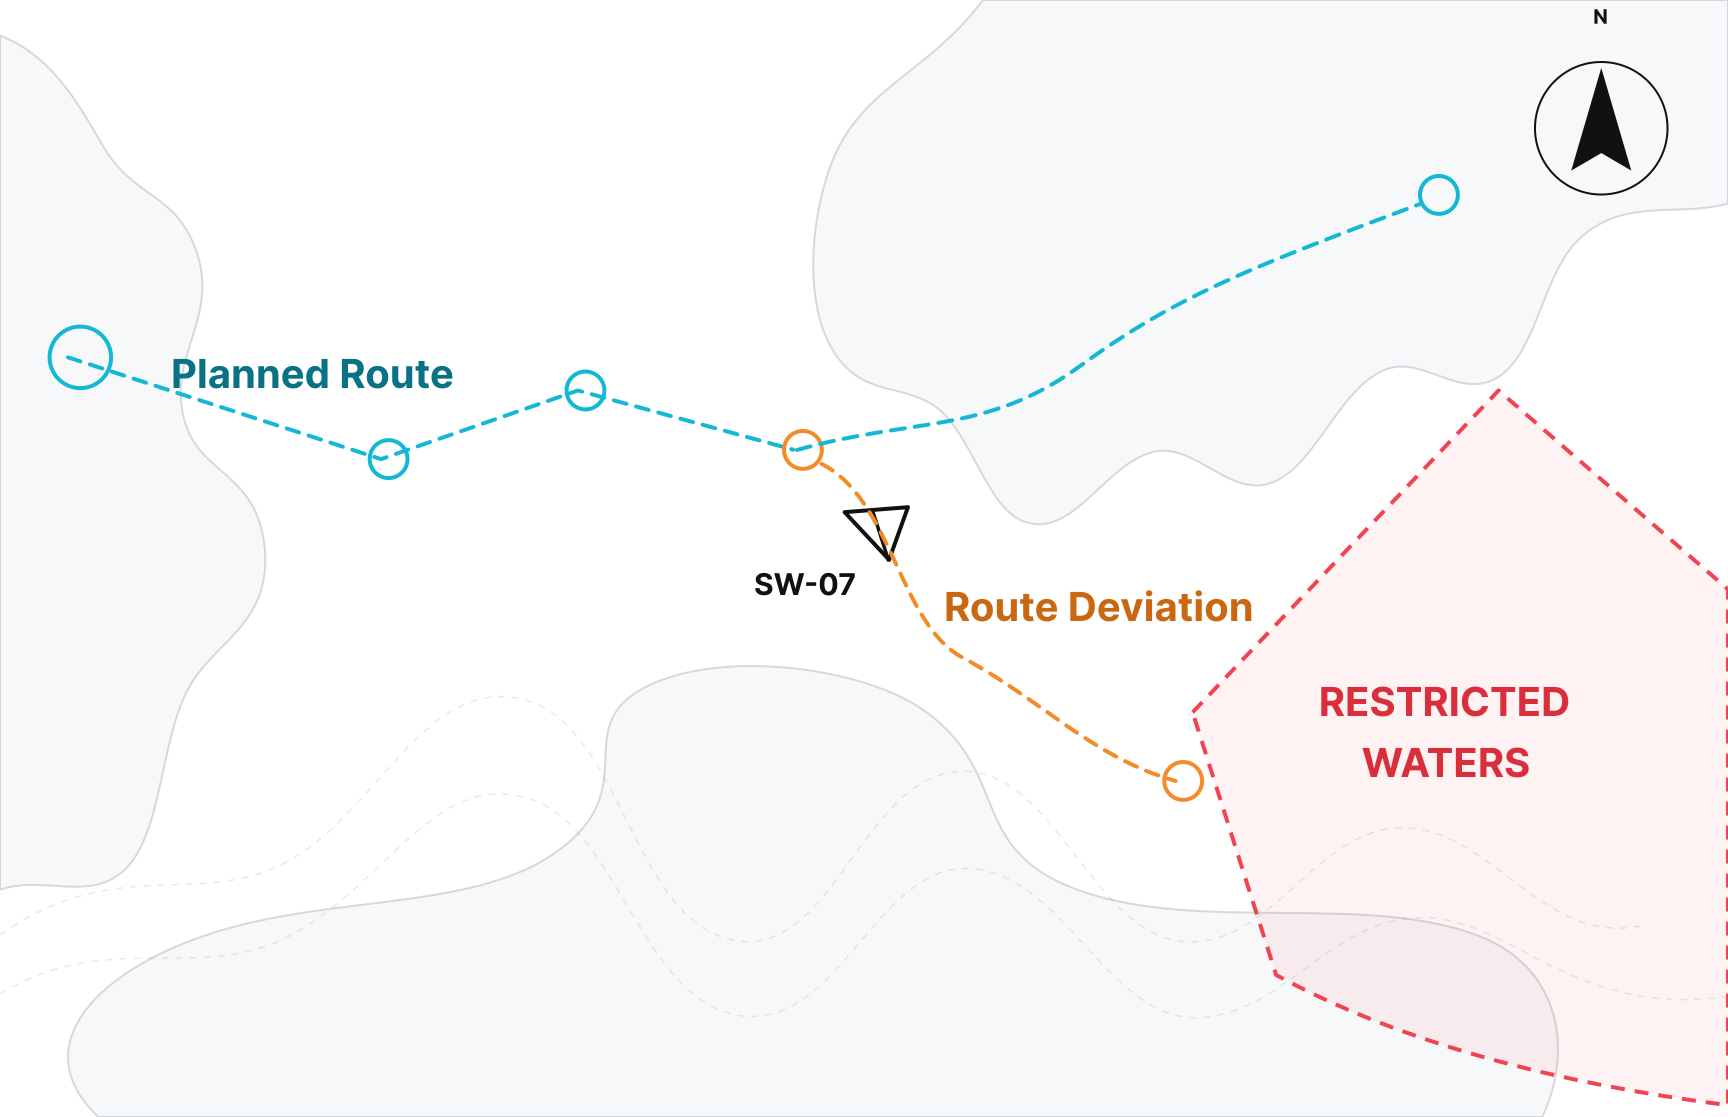
During a maritime surveillance mission, autonomous vessel SW-07 initiates a collision-avoidance maneuver. Strong ocean currents prevent it from returning to its approved route, increasing the risk of entering restricted waters.


A route deviation does not always indicate system failure. Operators must quickly determine whether the vessel is safely adapting or becoming a mission threat.

Resource: MarineTraffic Live Map and Fleet Dashboard, Pole Star Global, QGroundControl Plan, and etc.
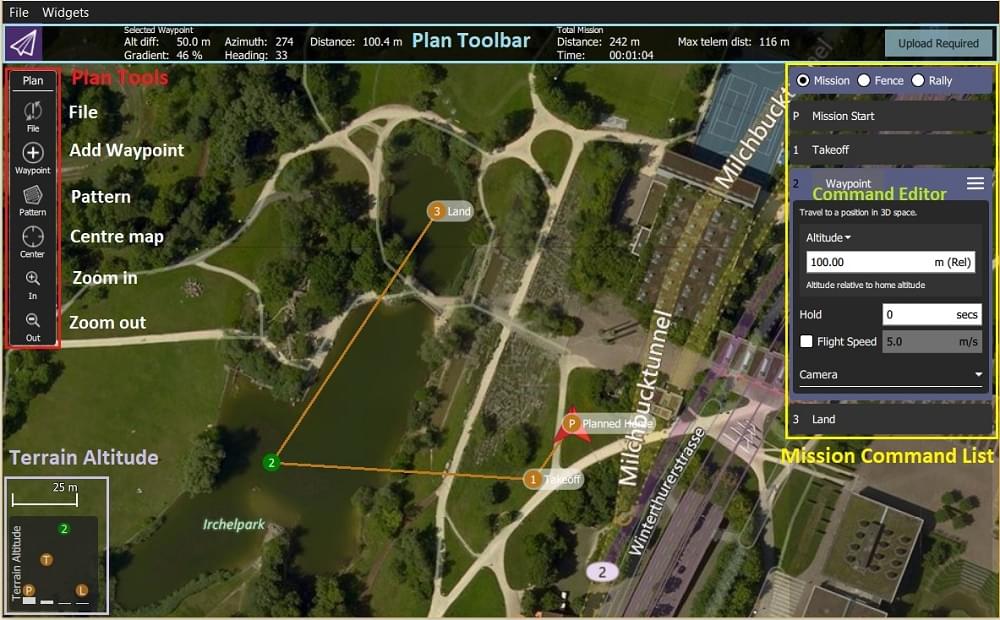
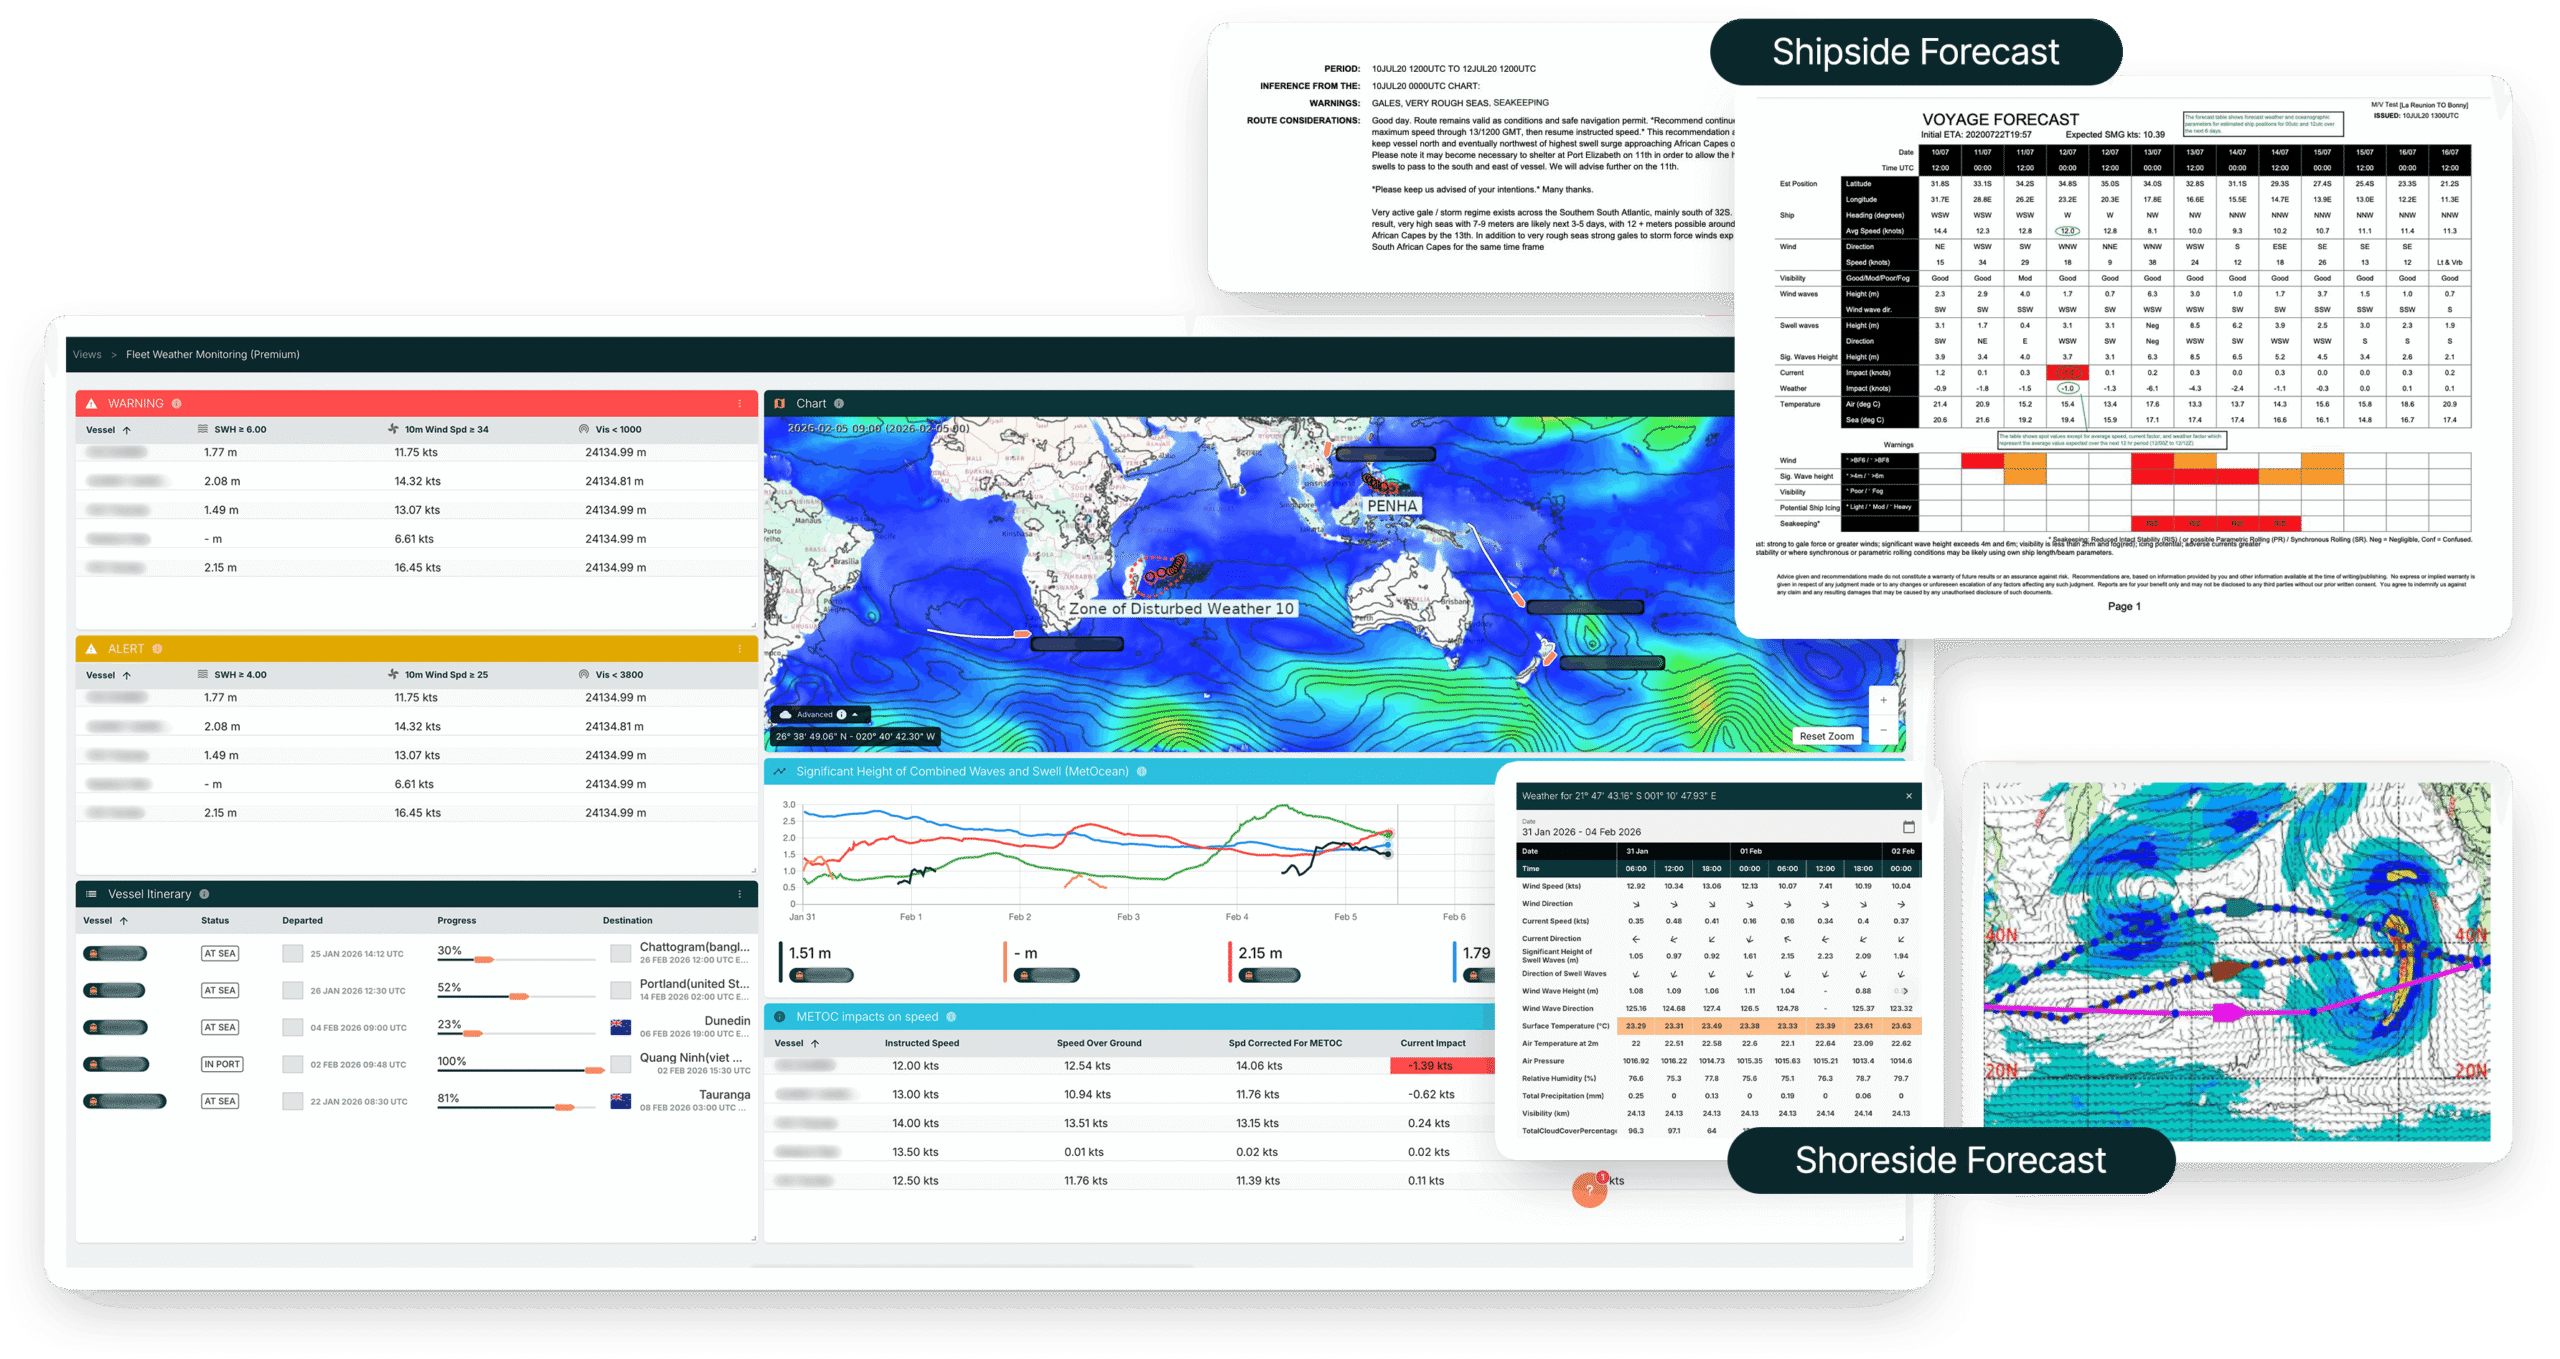
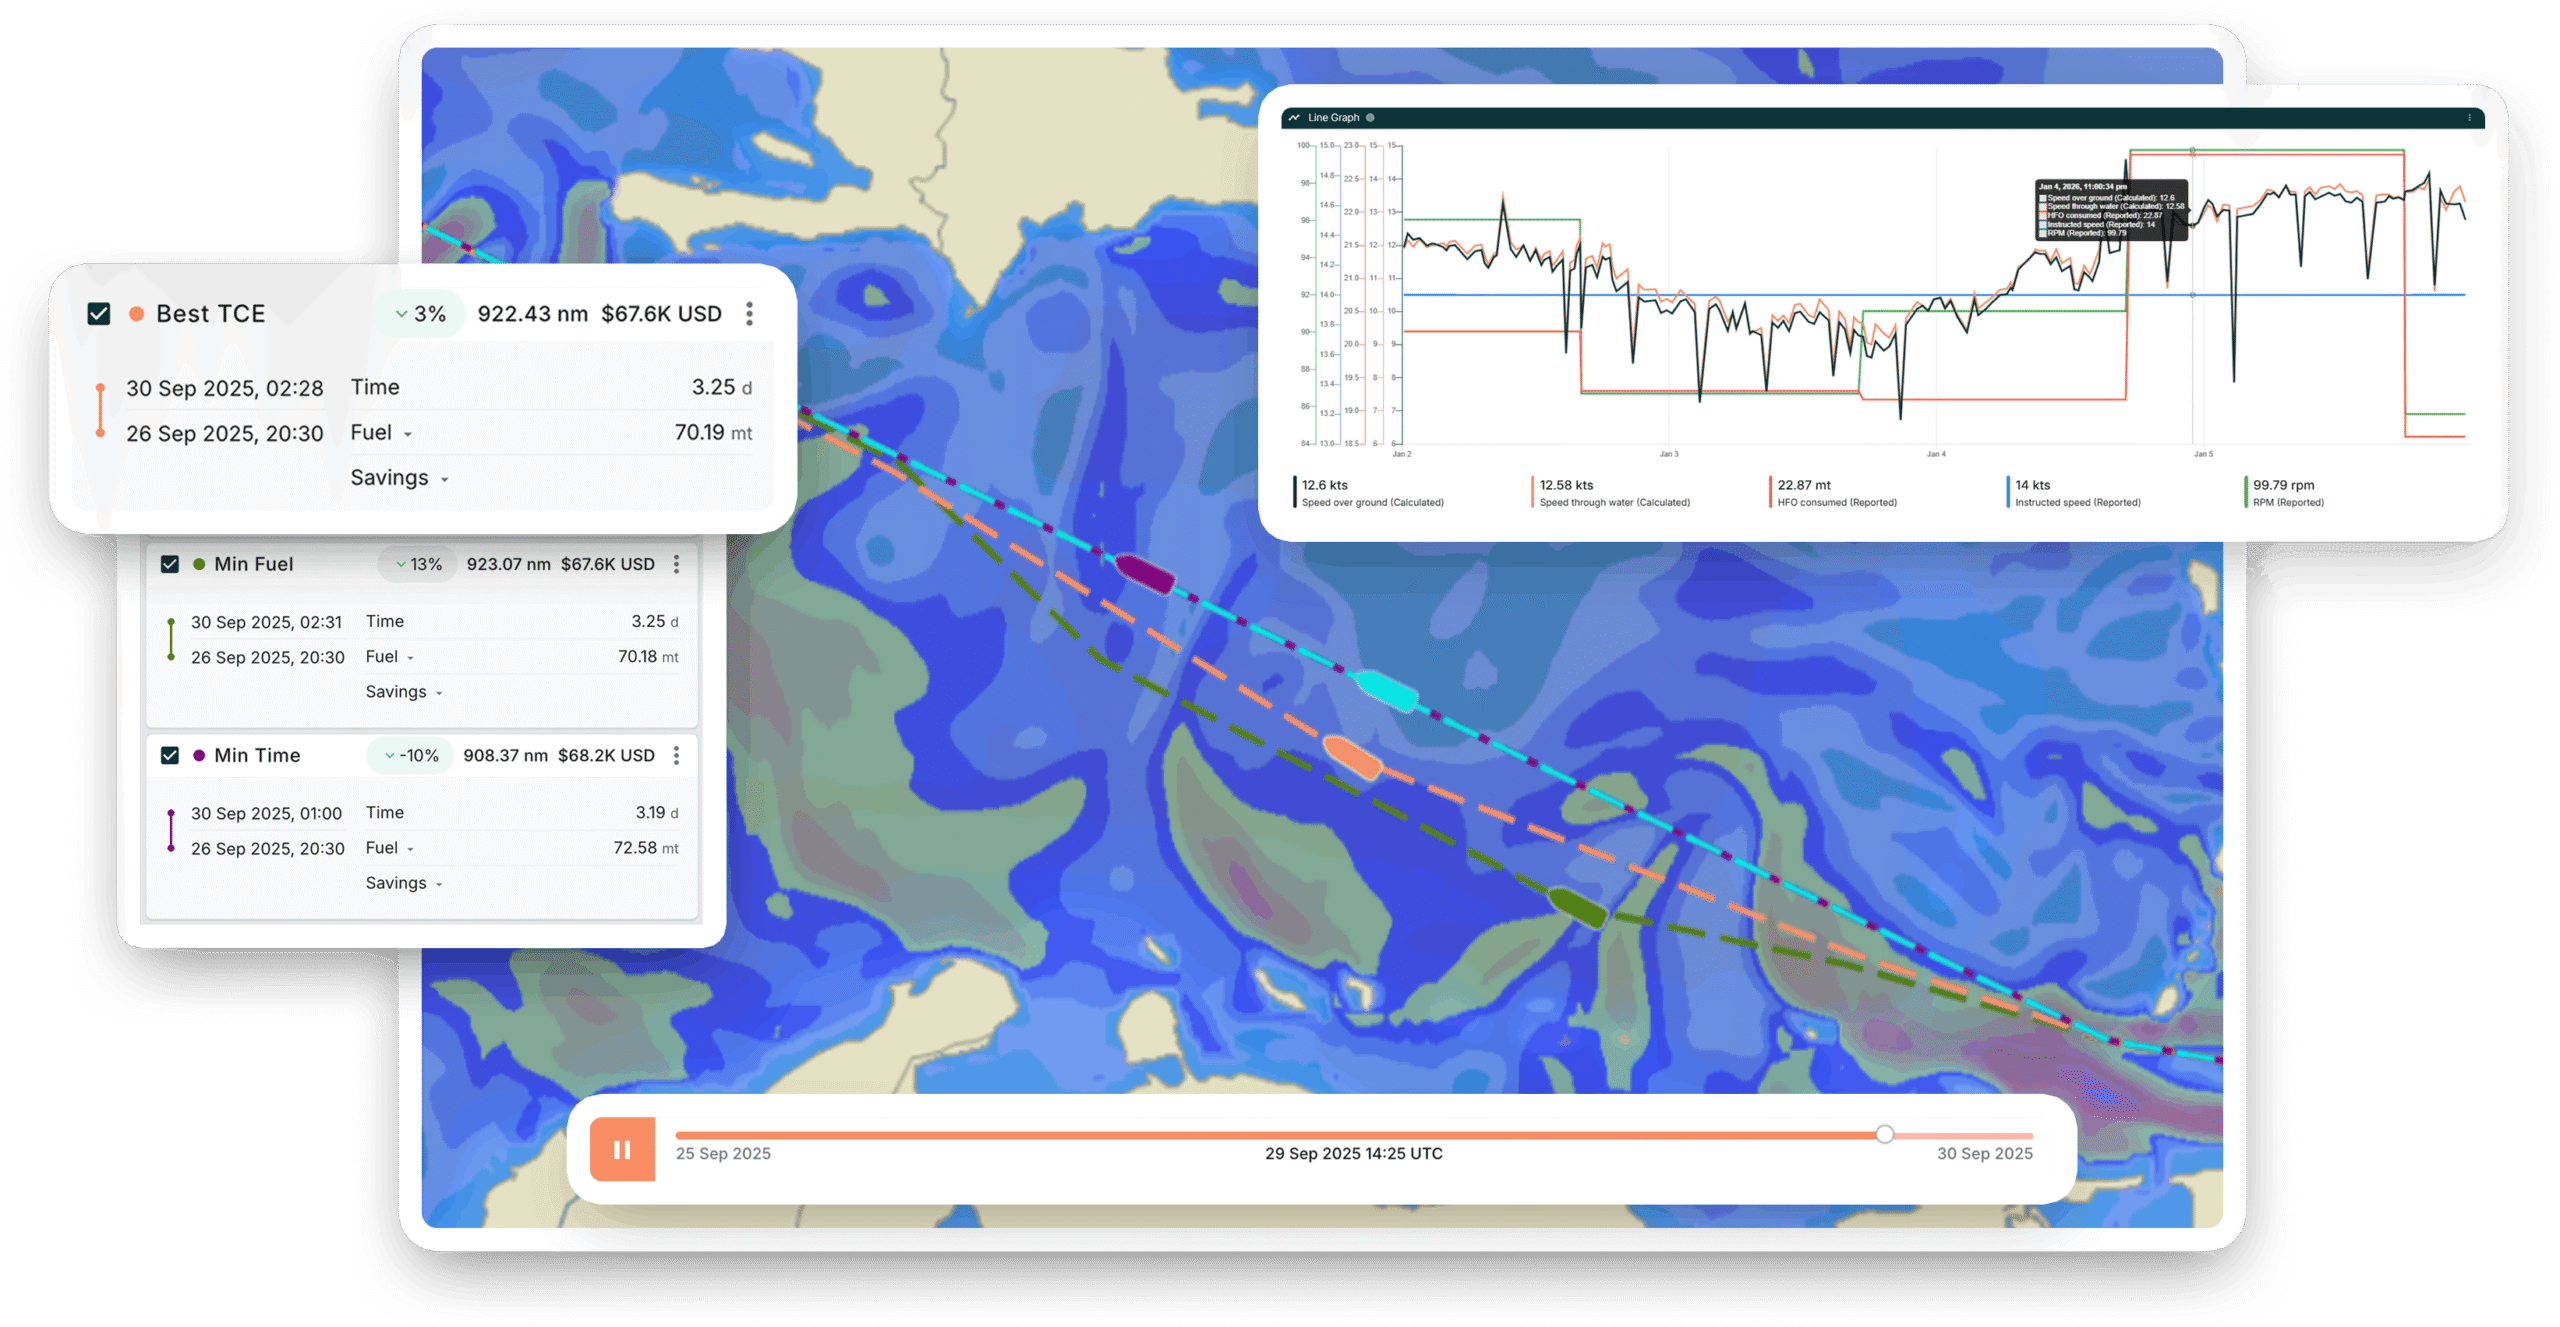
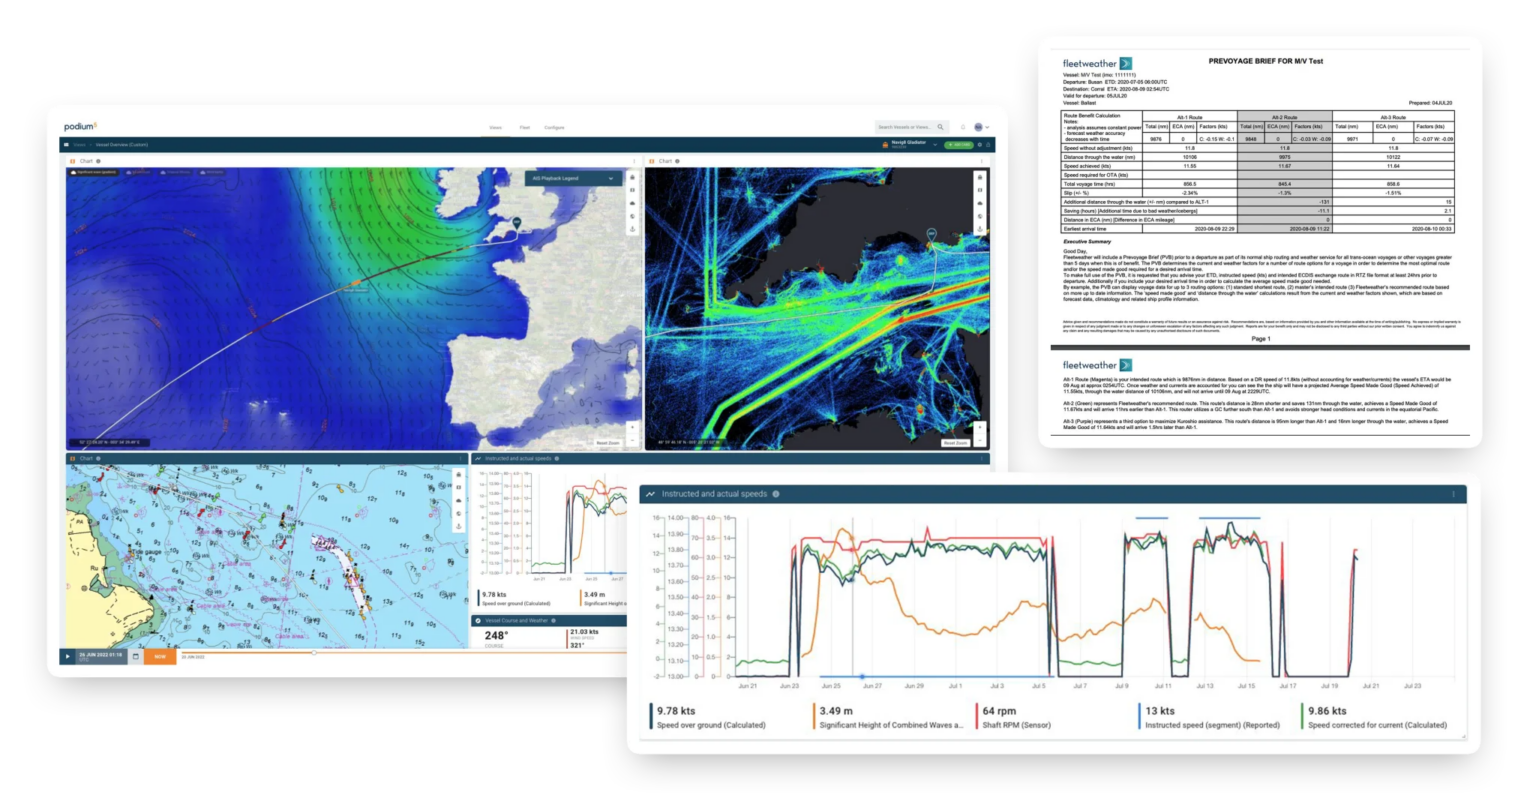
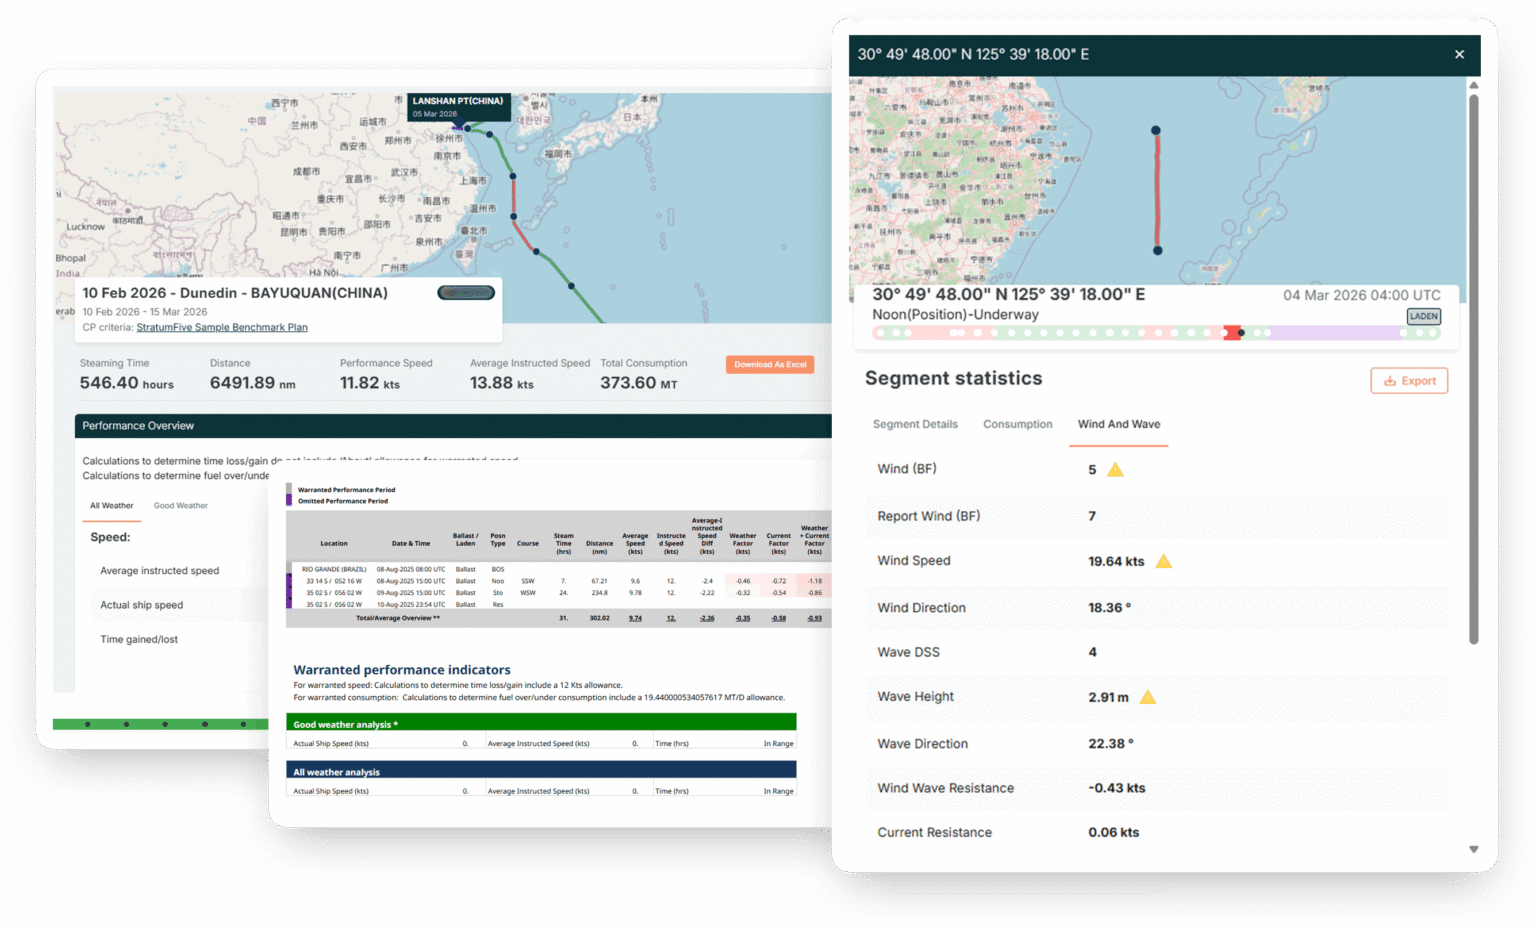
Operators need a fast and reliable way to understand the cause of a deviation, evaluate its risk, and select an appropriate response.
How might we move operators from alert detection to an informed response without overwhelming them with raw system data?

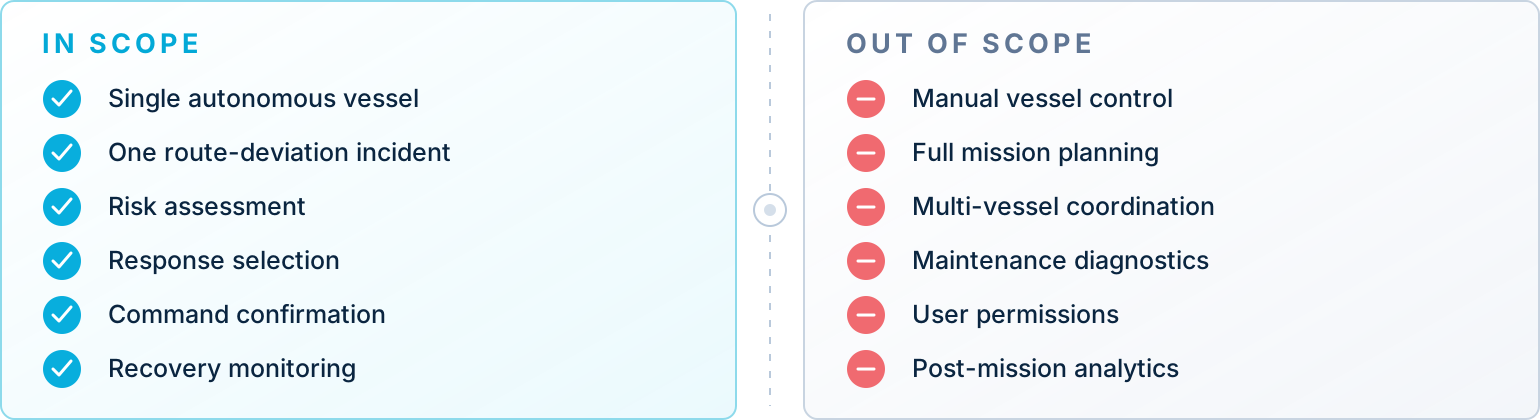
Route-deviation detection, incident investigation, response approval, and command verification.

Because direct access to active maritime-autonomy operators was limited, I combined secondary research, interface analysis, and feedback from proxy users familiar with operational or complex digital systems.
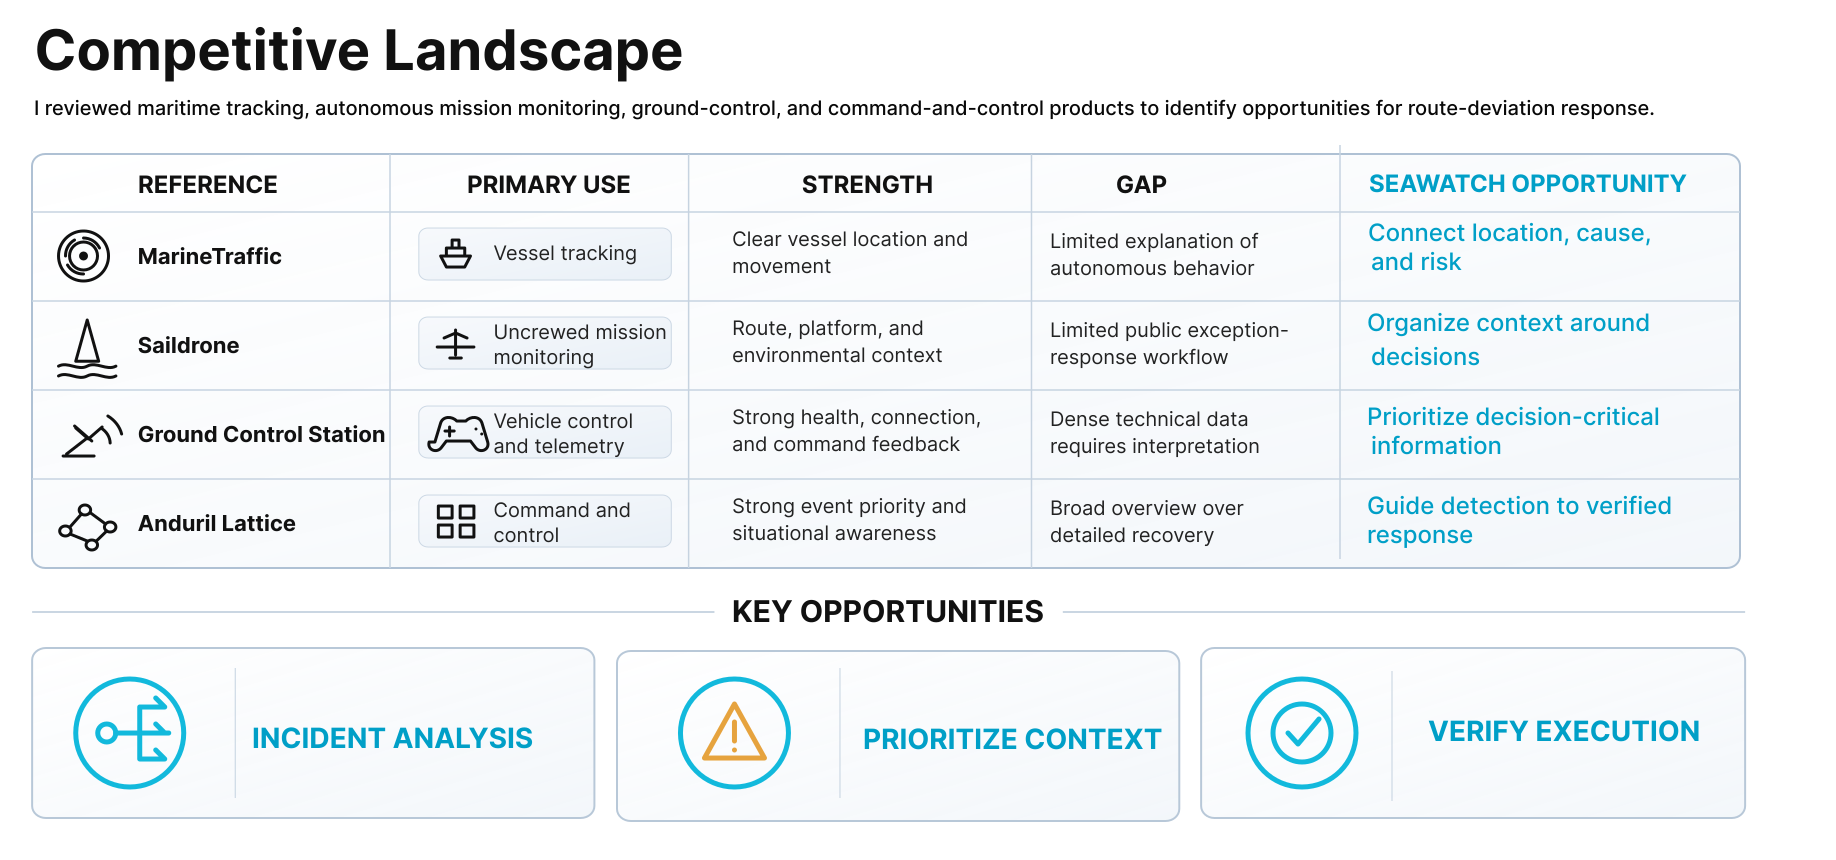
Selected Sources: Saildrone Mission Portal, MarineTraffic Live Map and Fleet Dashboard, QGroundControl Plan and Fly Views, Anduril Lattice Command & Control, OpenCPN, and U.S. Coast Guard AIS documentation.
The Scope
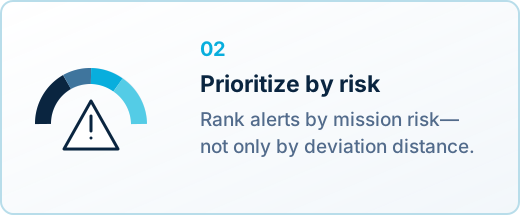
Design Principle

SW-07 is outside its approved route corridor and approaching restricted waters. Determine why the vessel deviated and select the safest response. The User is Maritime Operator.
Primary Persona: Alex Christopher
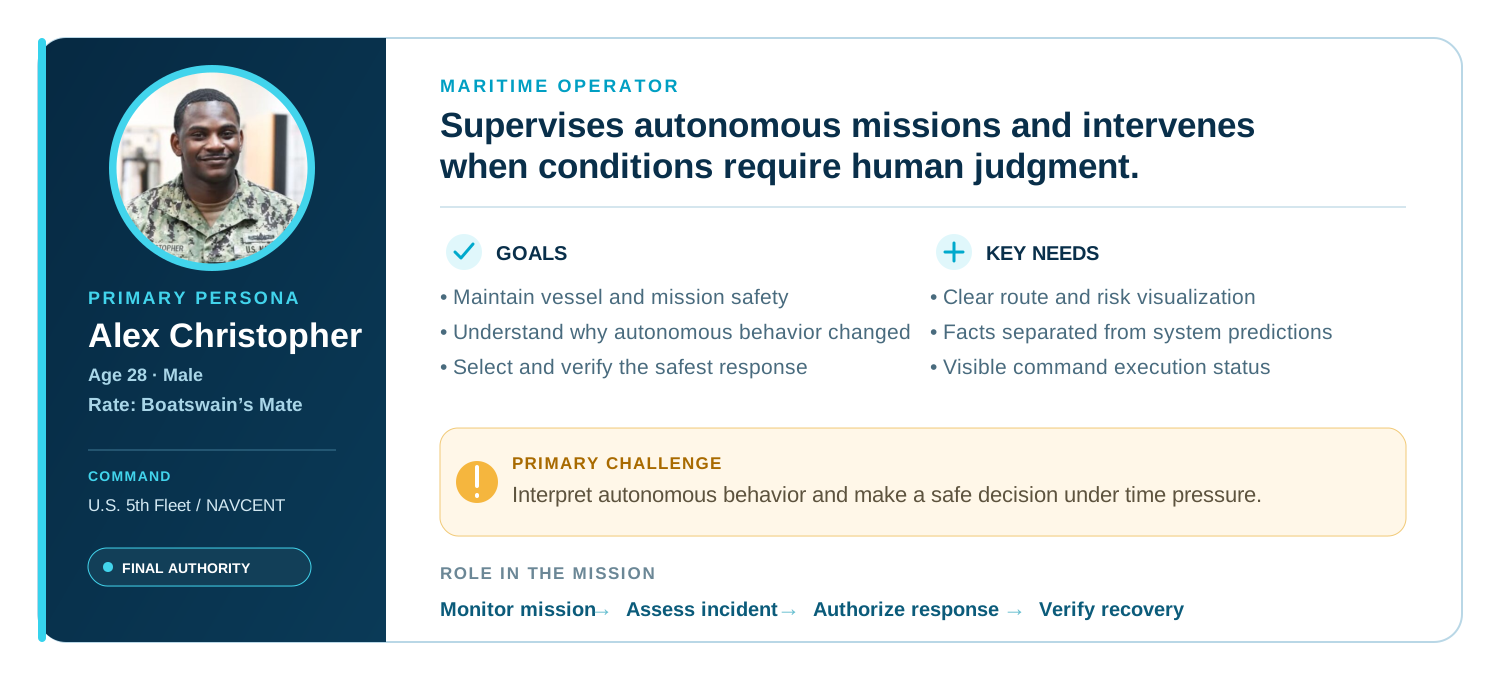
Core task workflow - Maritime Operator
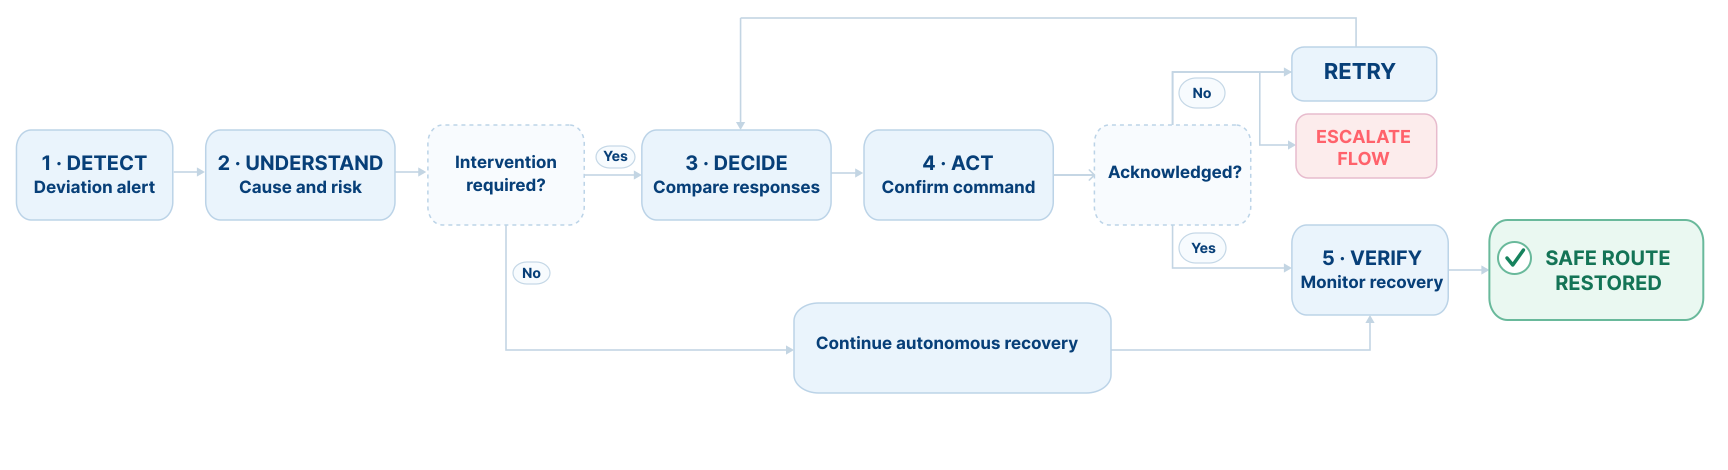
User Flow - Maritime Operator
The workflow guides the operator from deviation detection to a verified recovery while preserving operator authority at critical decision points.
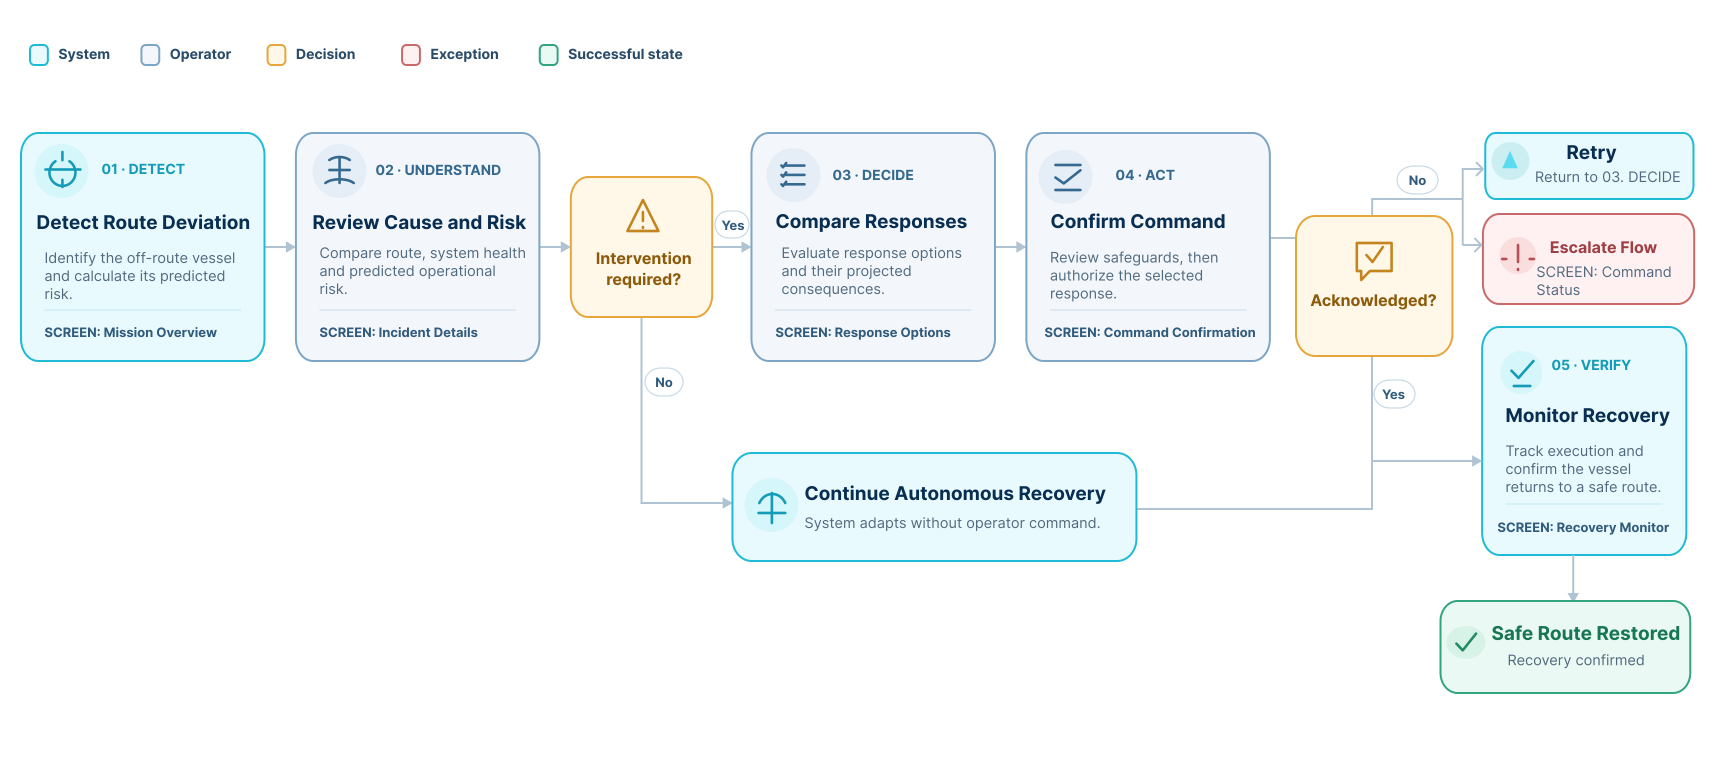
The workflow separates understanding, decision-making, command execution, and recovery verification to reduce premature or unnecessary intervention.
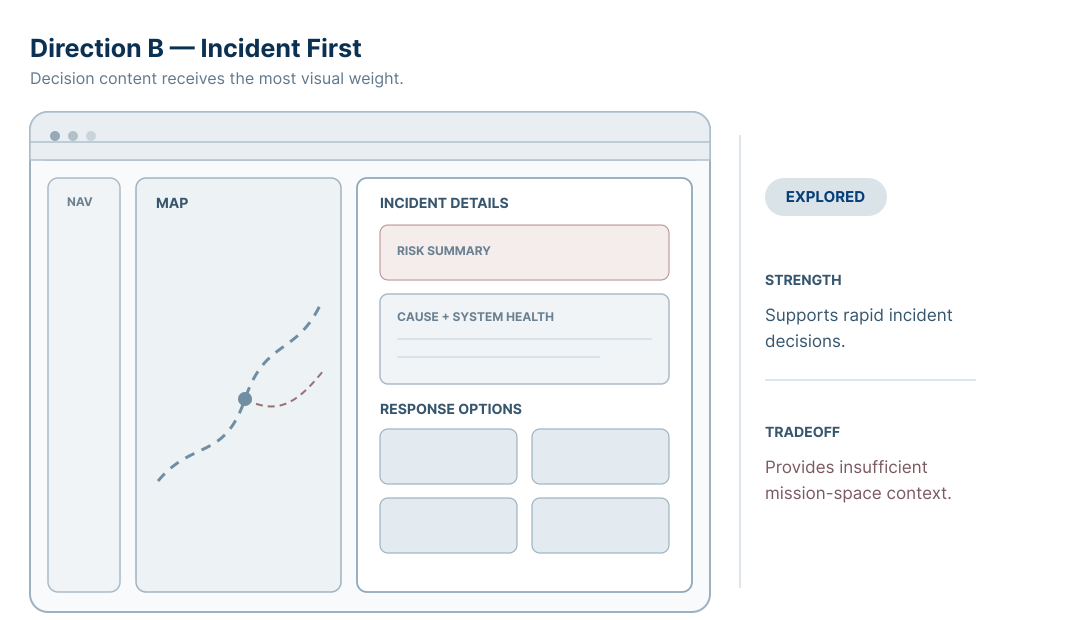
I explored multiple ways to organize route context, vessel status, risk information, and response controls without forcing the operator to leave the active incident.
What information must remain visible while the operator investigates an incident?
1). Initial Wireframe Directions


2). Information Progression Study
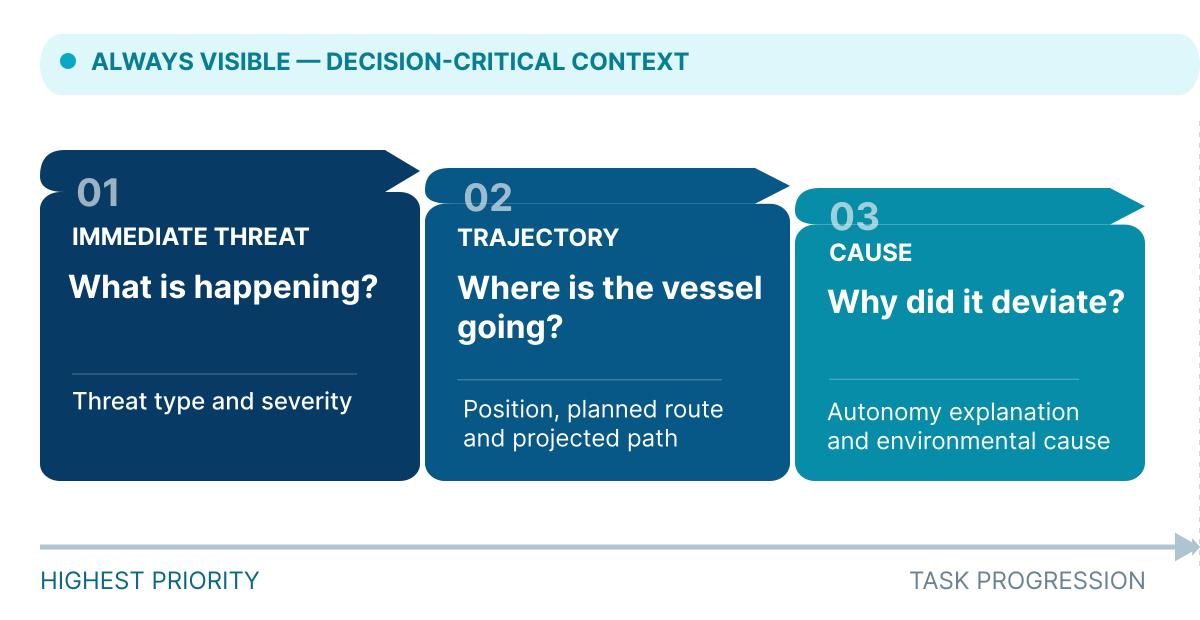
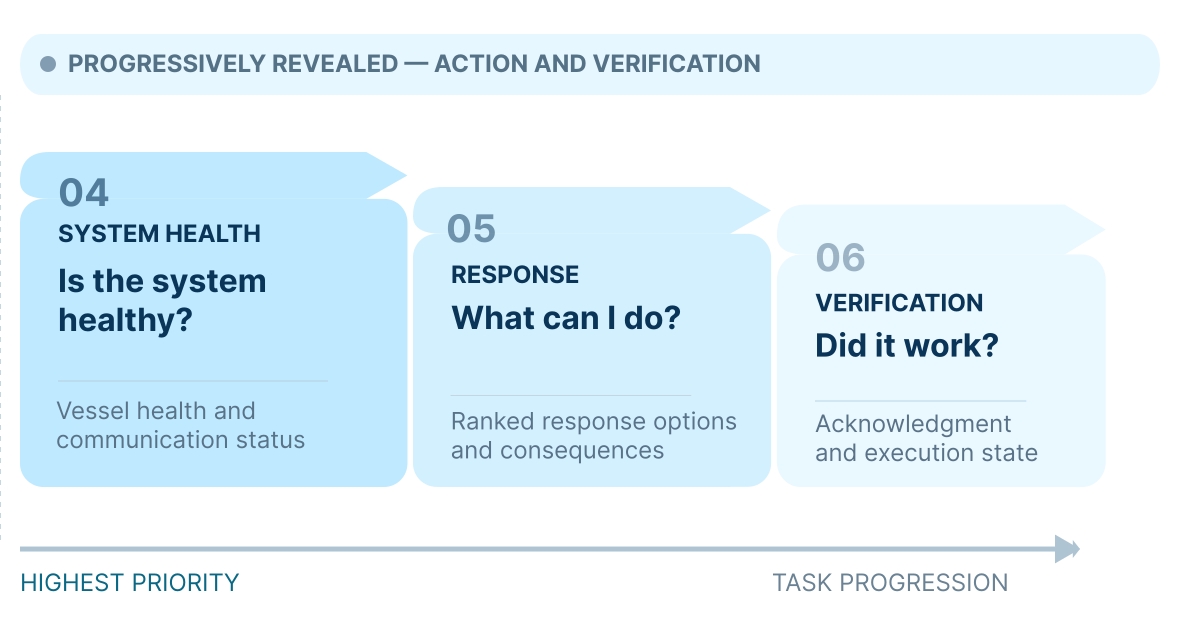
The interface prioritizes operational meaning before technical detail: threat, trajectory, and cause remain visible before controls are introduced.


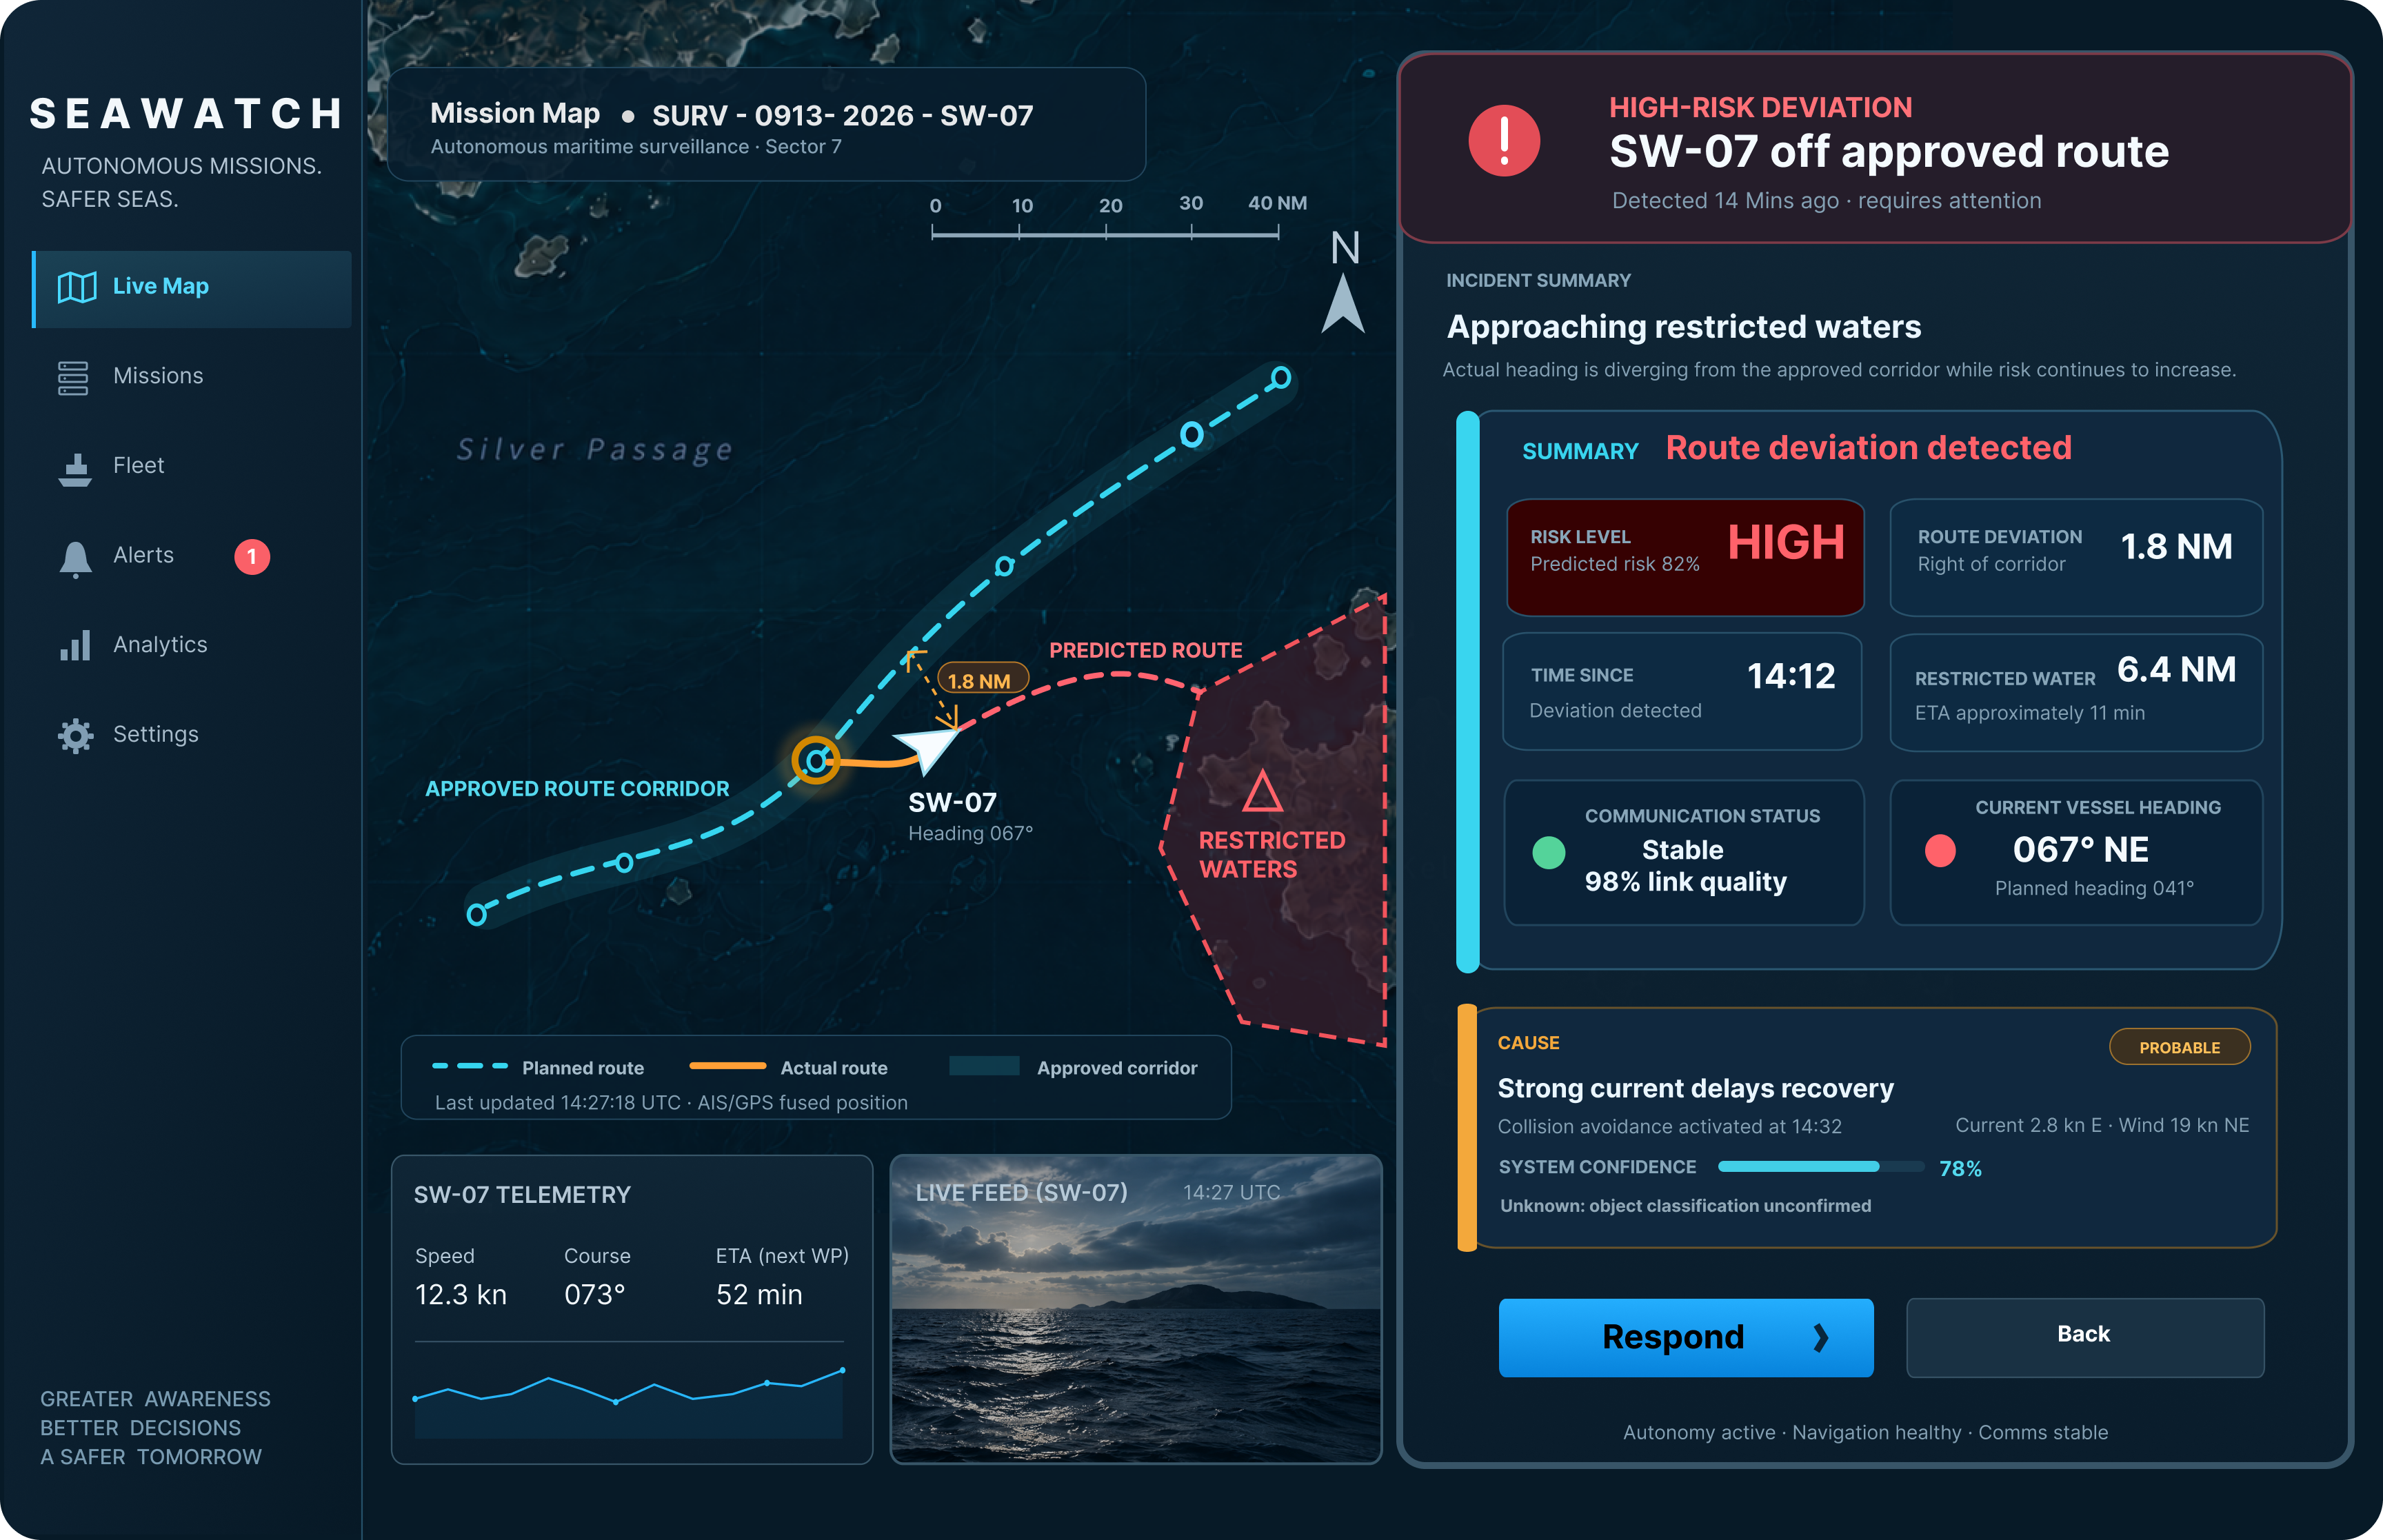
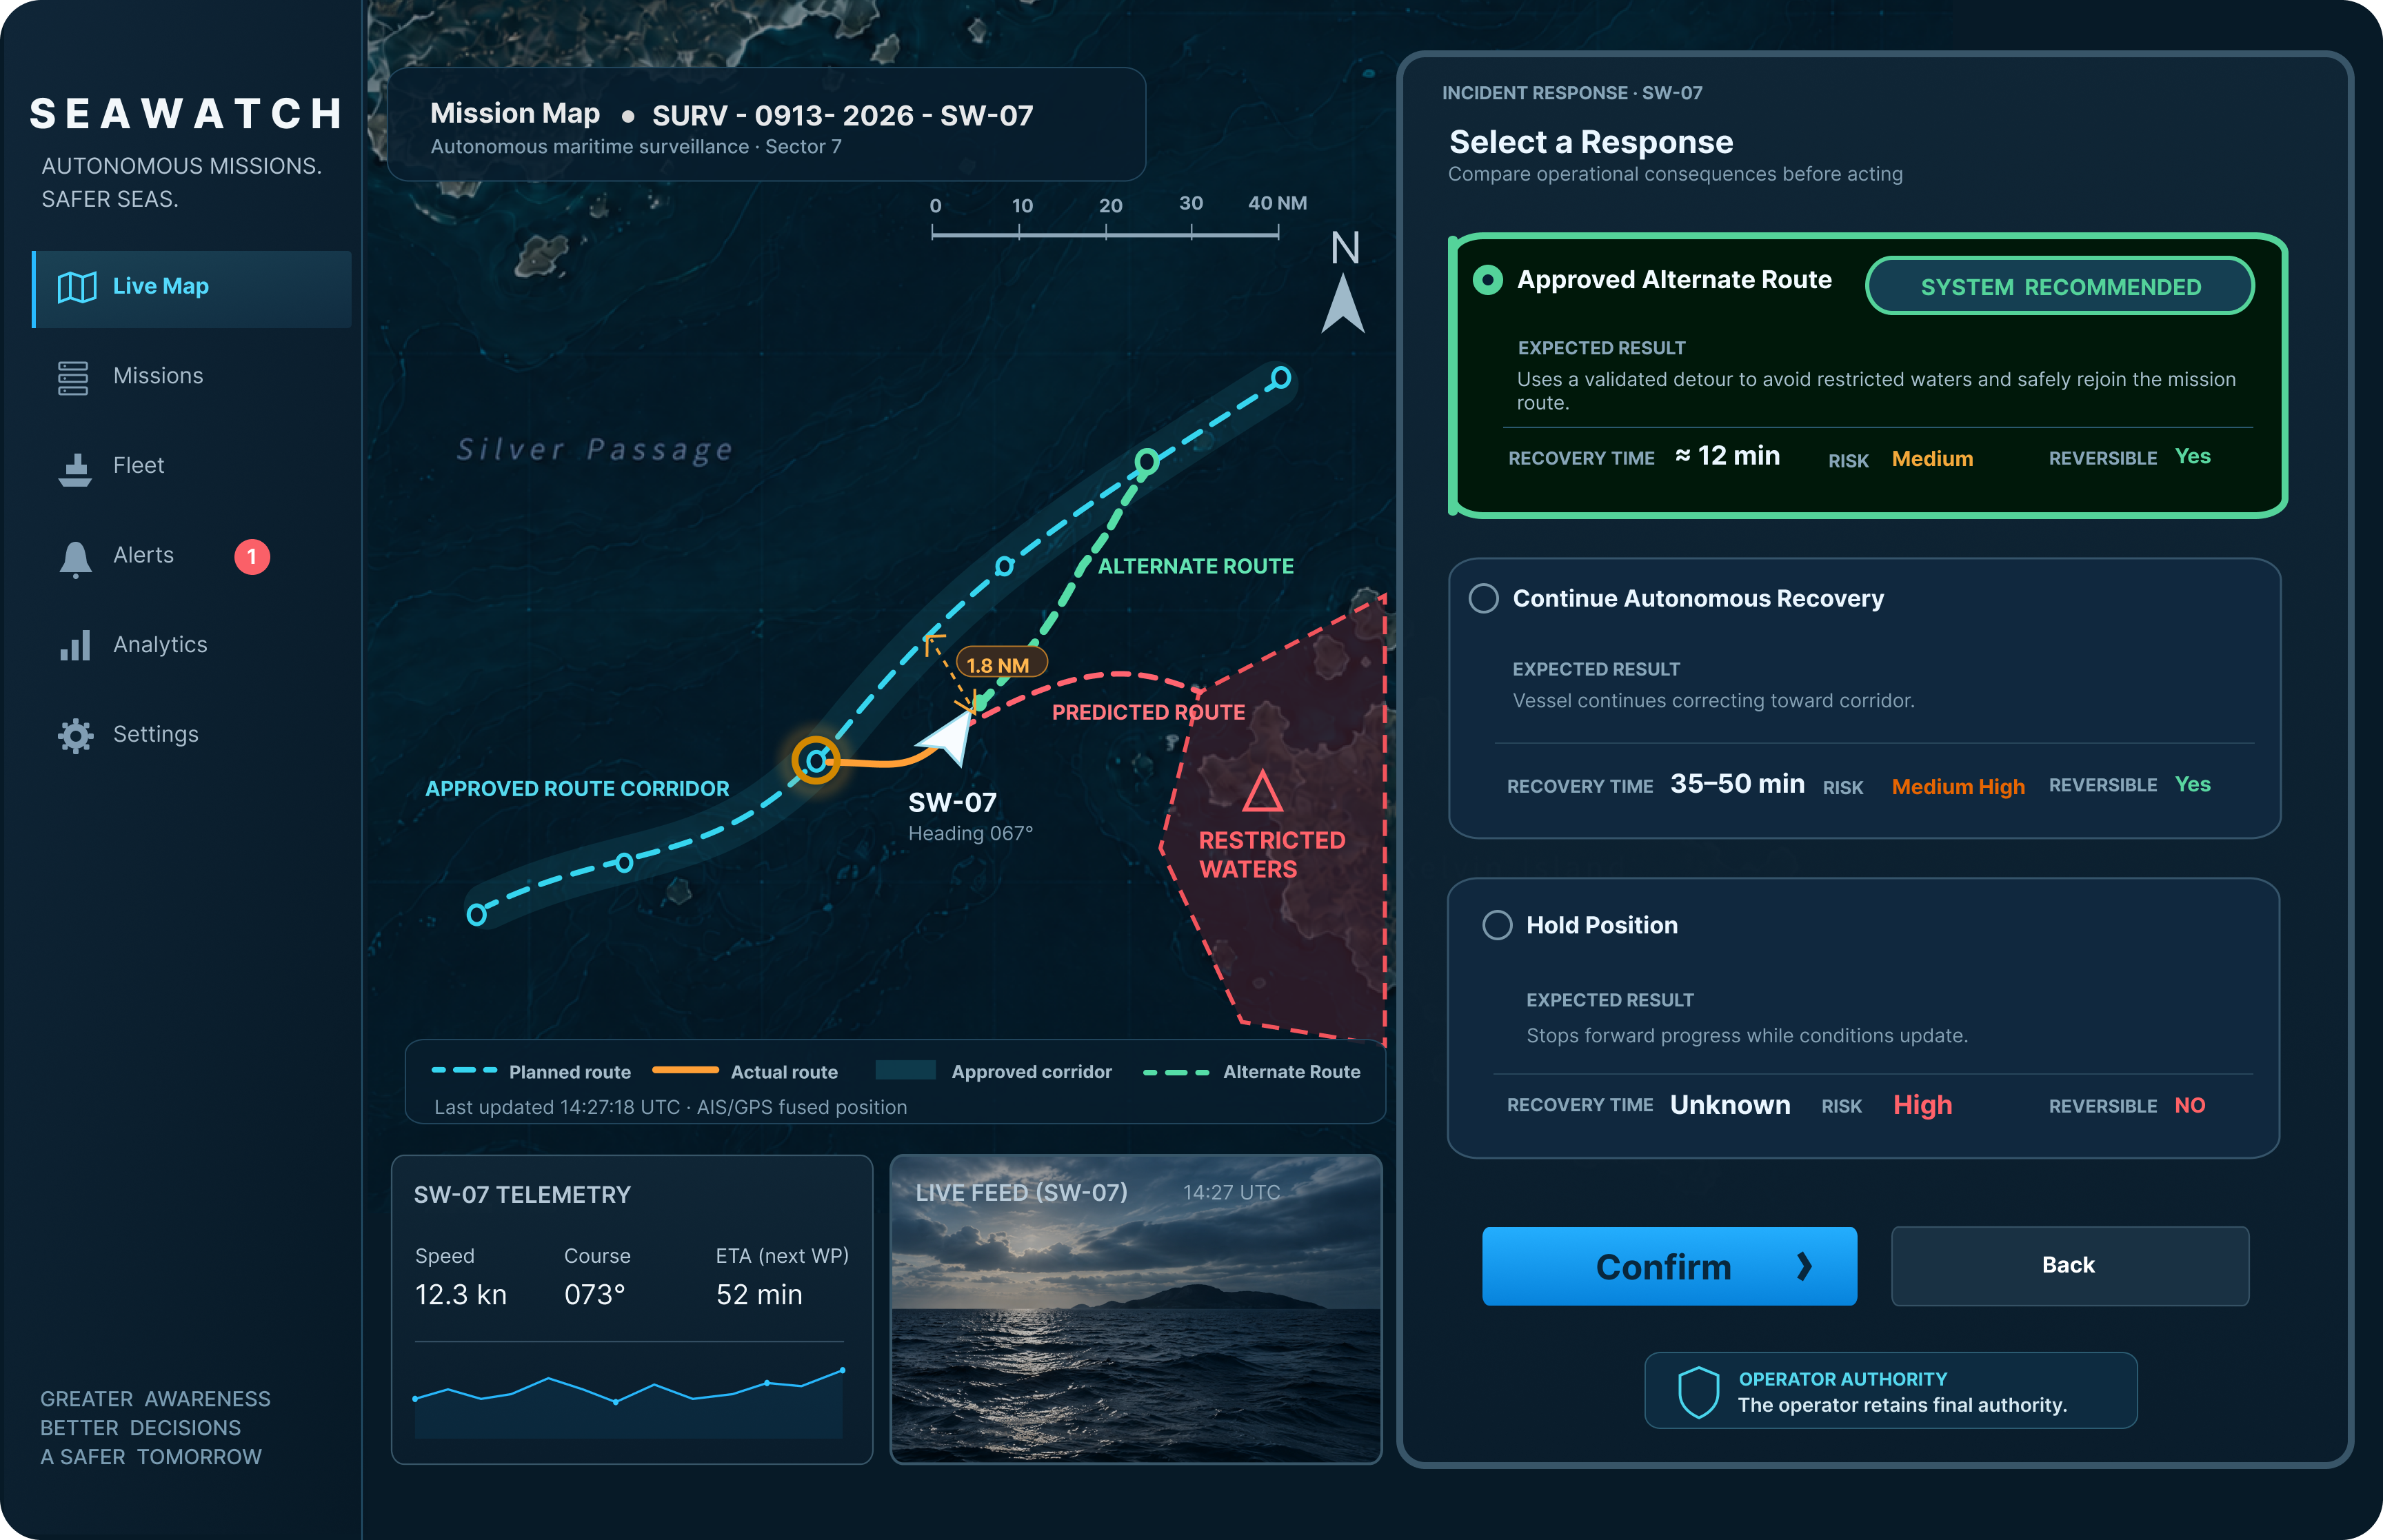
I selected a map-first layout with a persistent, decision-centered Incident Panel. Threat, trajectory, cause, and system health remain visible while response options progressively reveal their expected consequences.
The initial alert communicates what happened, which vessel is affected, and why the incident requires attention—without forcing the operator to leave the main mission view.
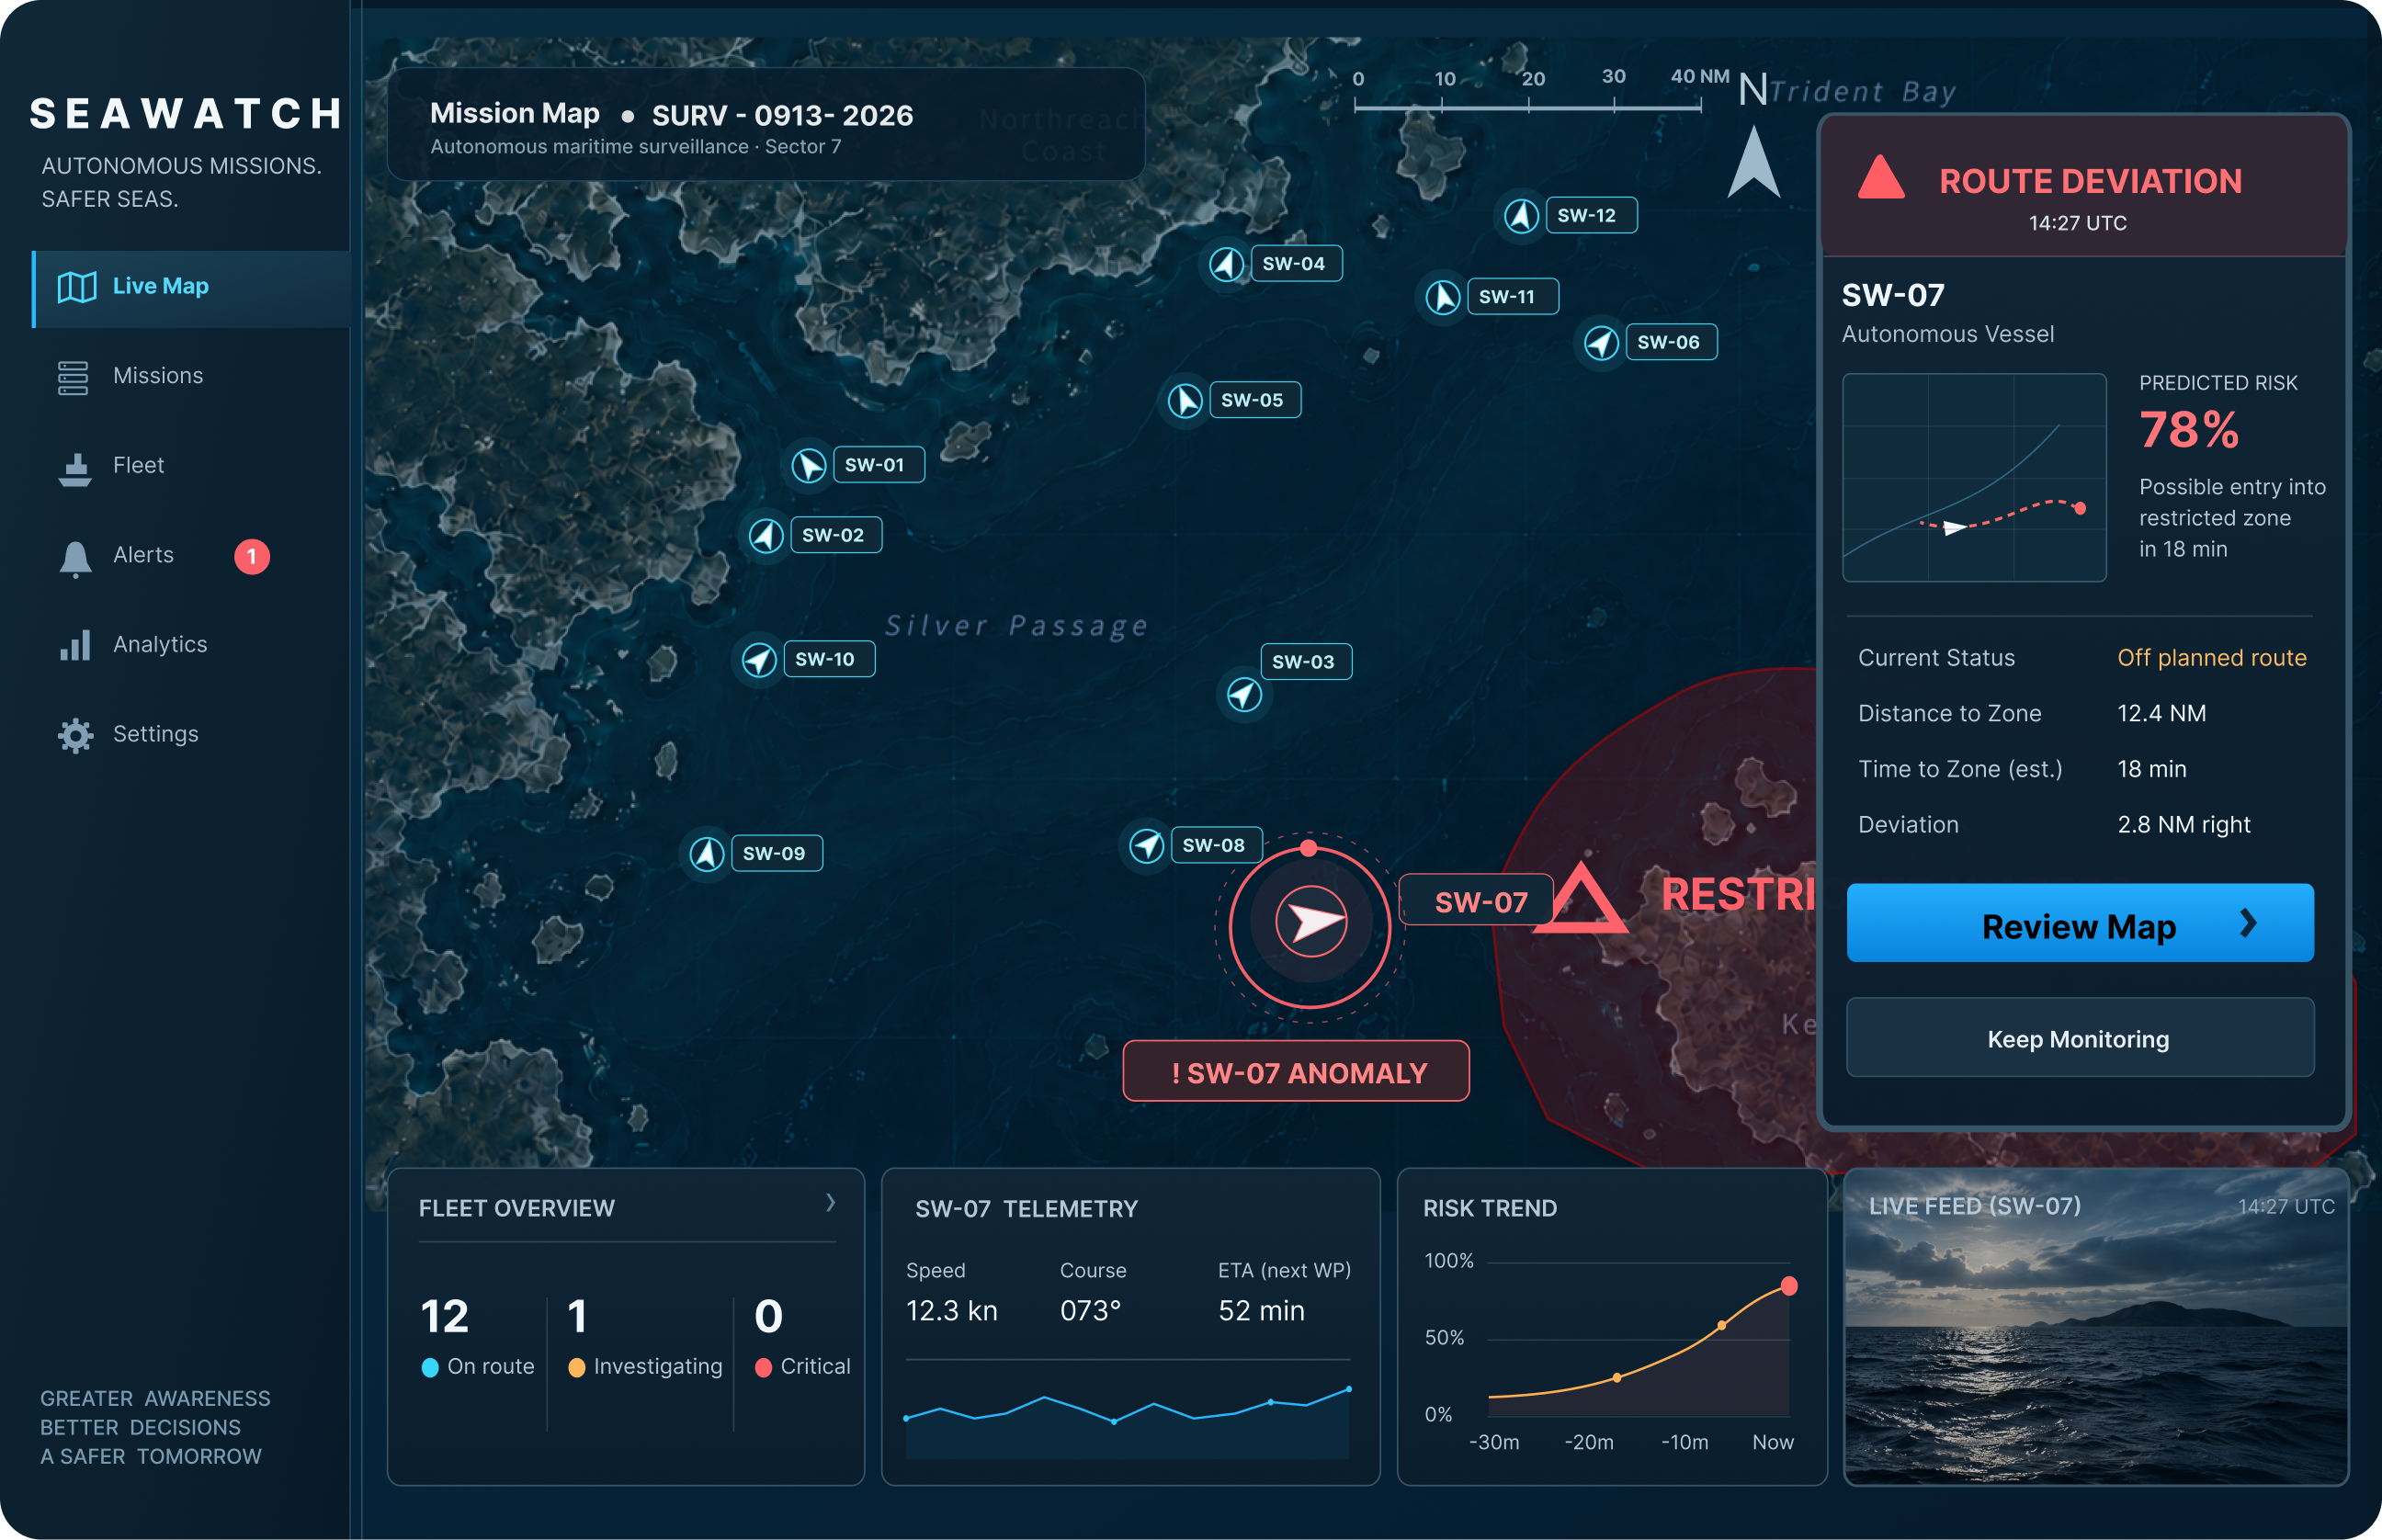

Instead of presenting raw telemetry equally, SeaWatch organizes information around the operator’s immediate questions: What happened, why did it happen, and what could happen next?

Response options are framed by operational consequences, helping the operator compare decisions rather than interpret technical commands.

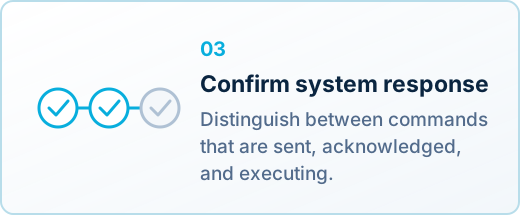
SeaWatch separates command submission from vehicle acknowledgment and execution so the operator always understands the real system state.
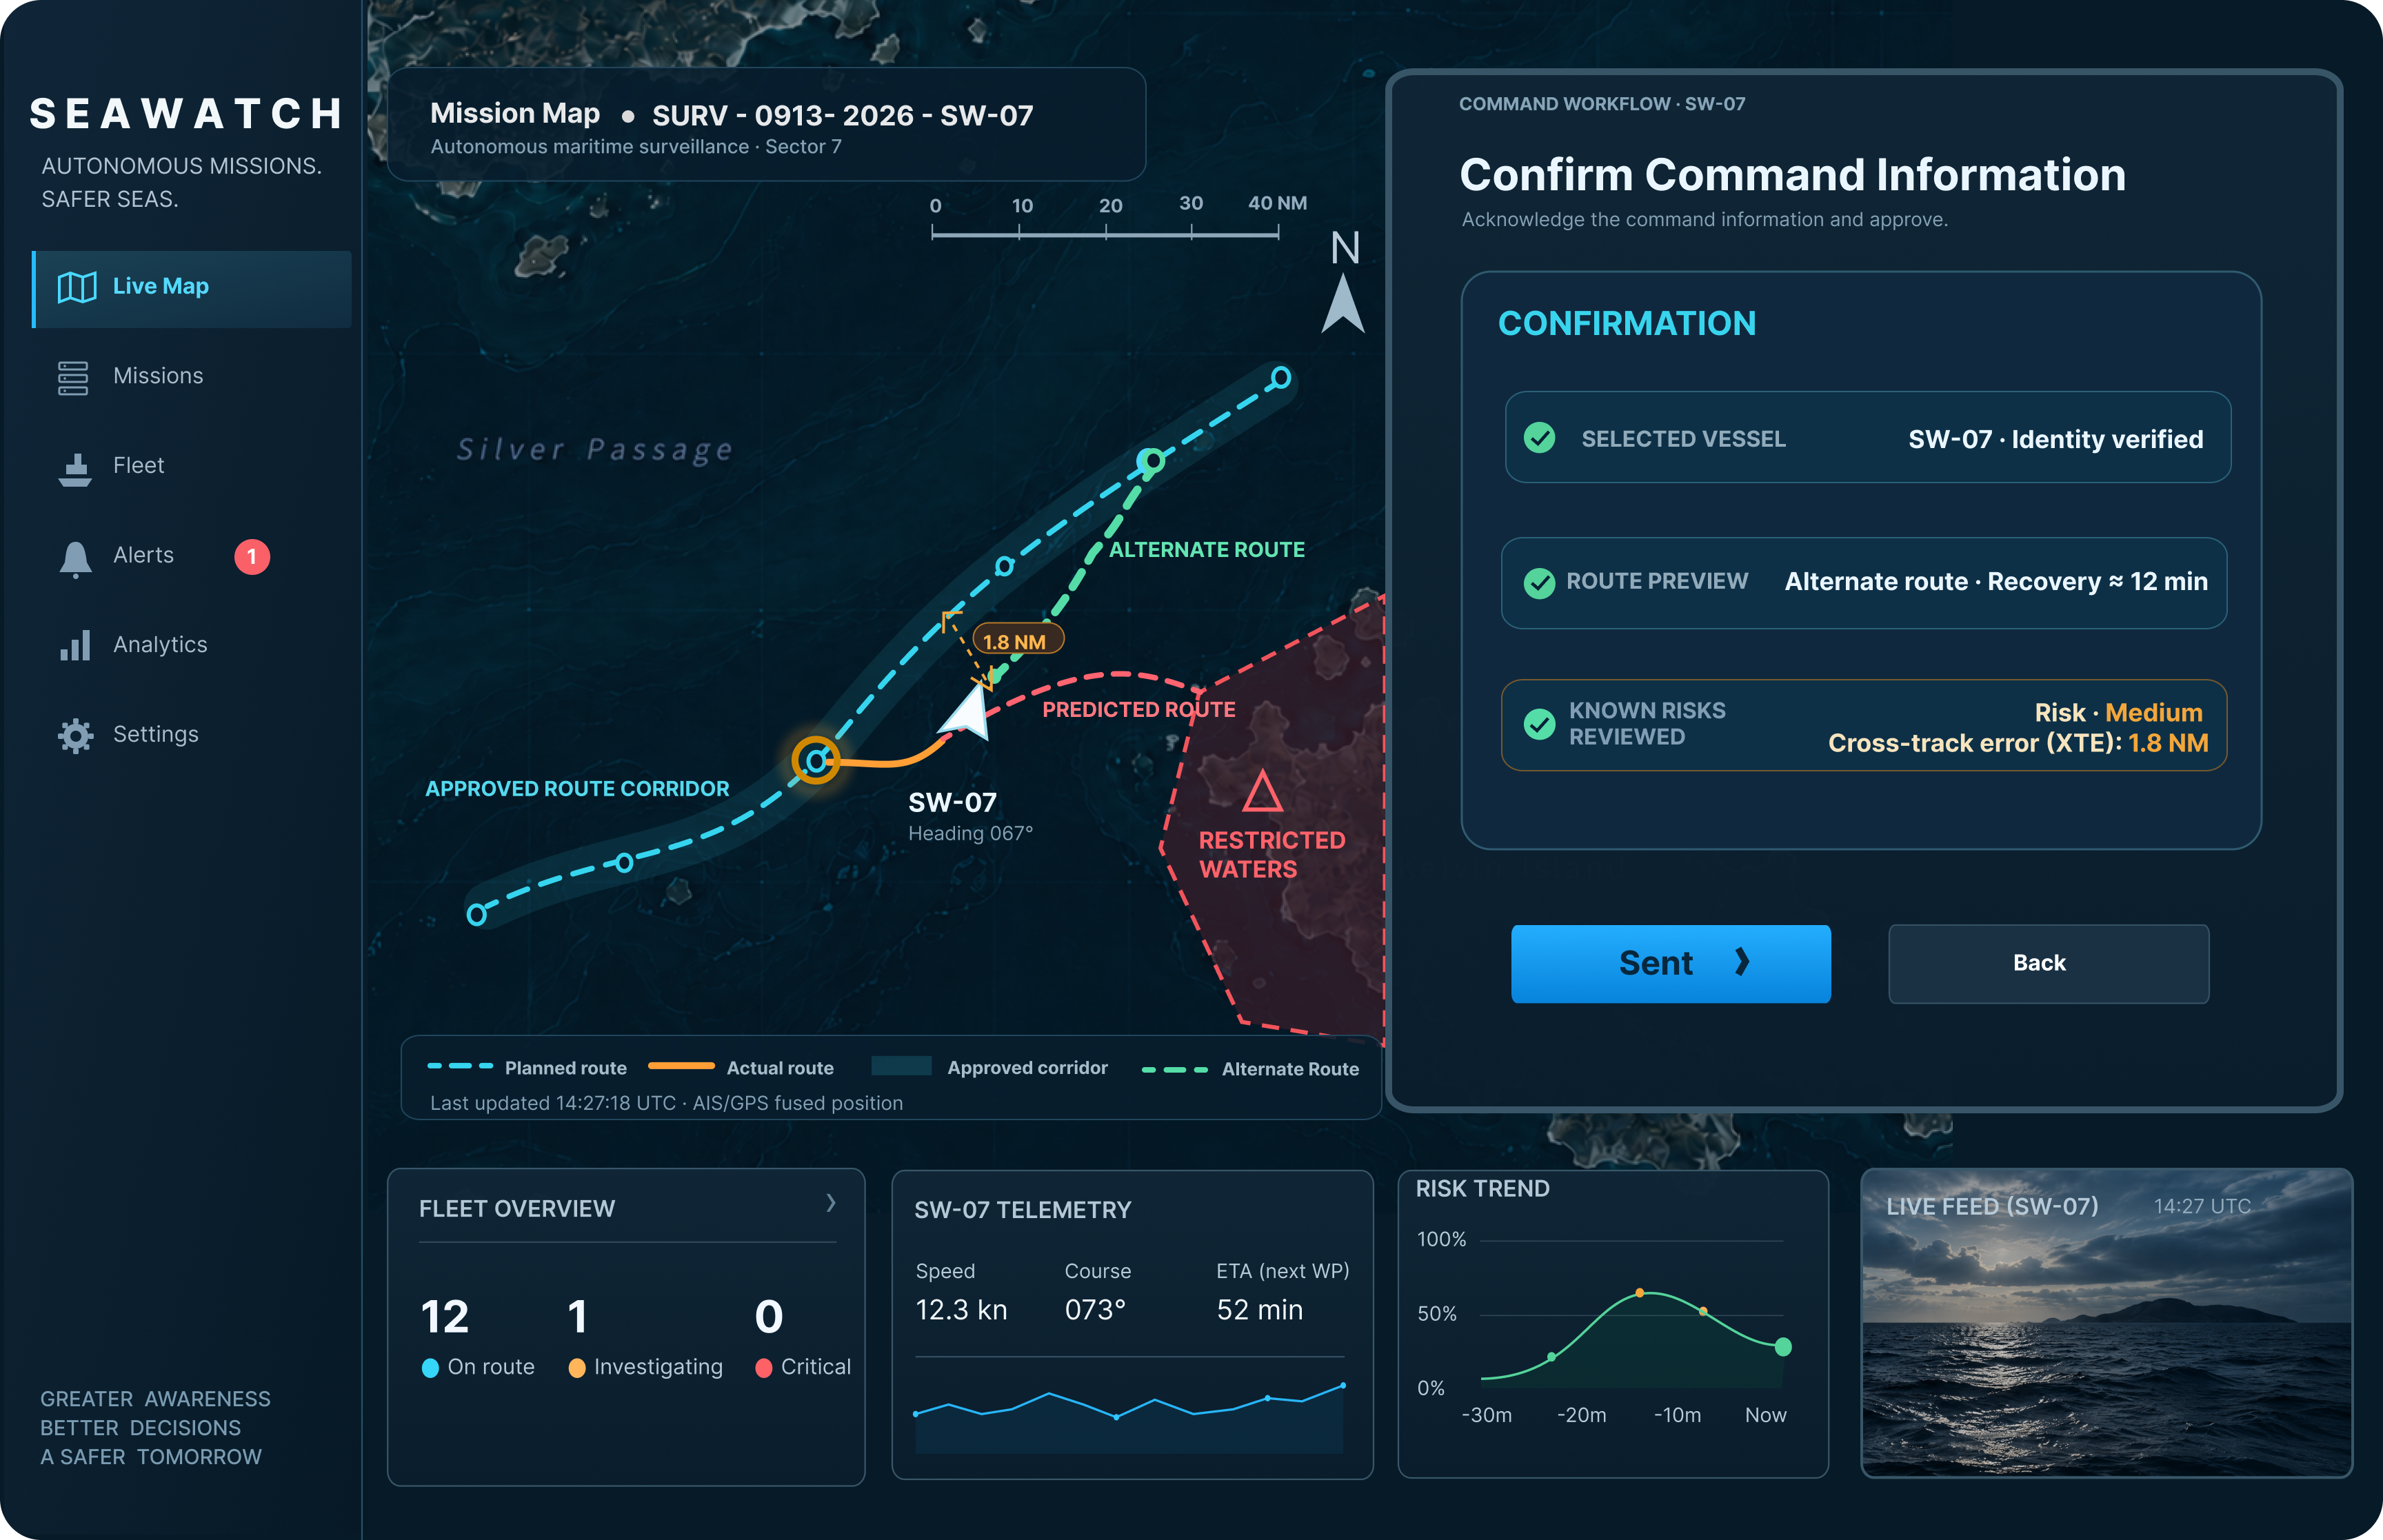
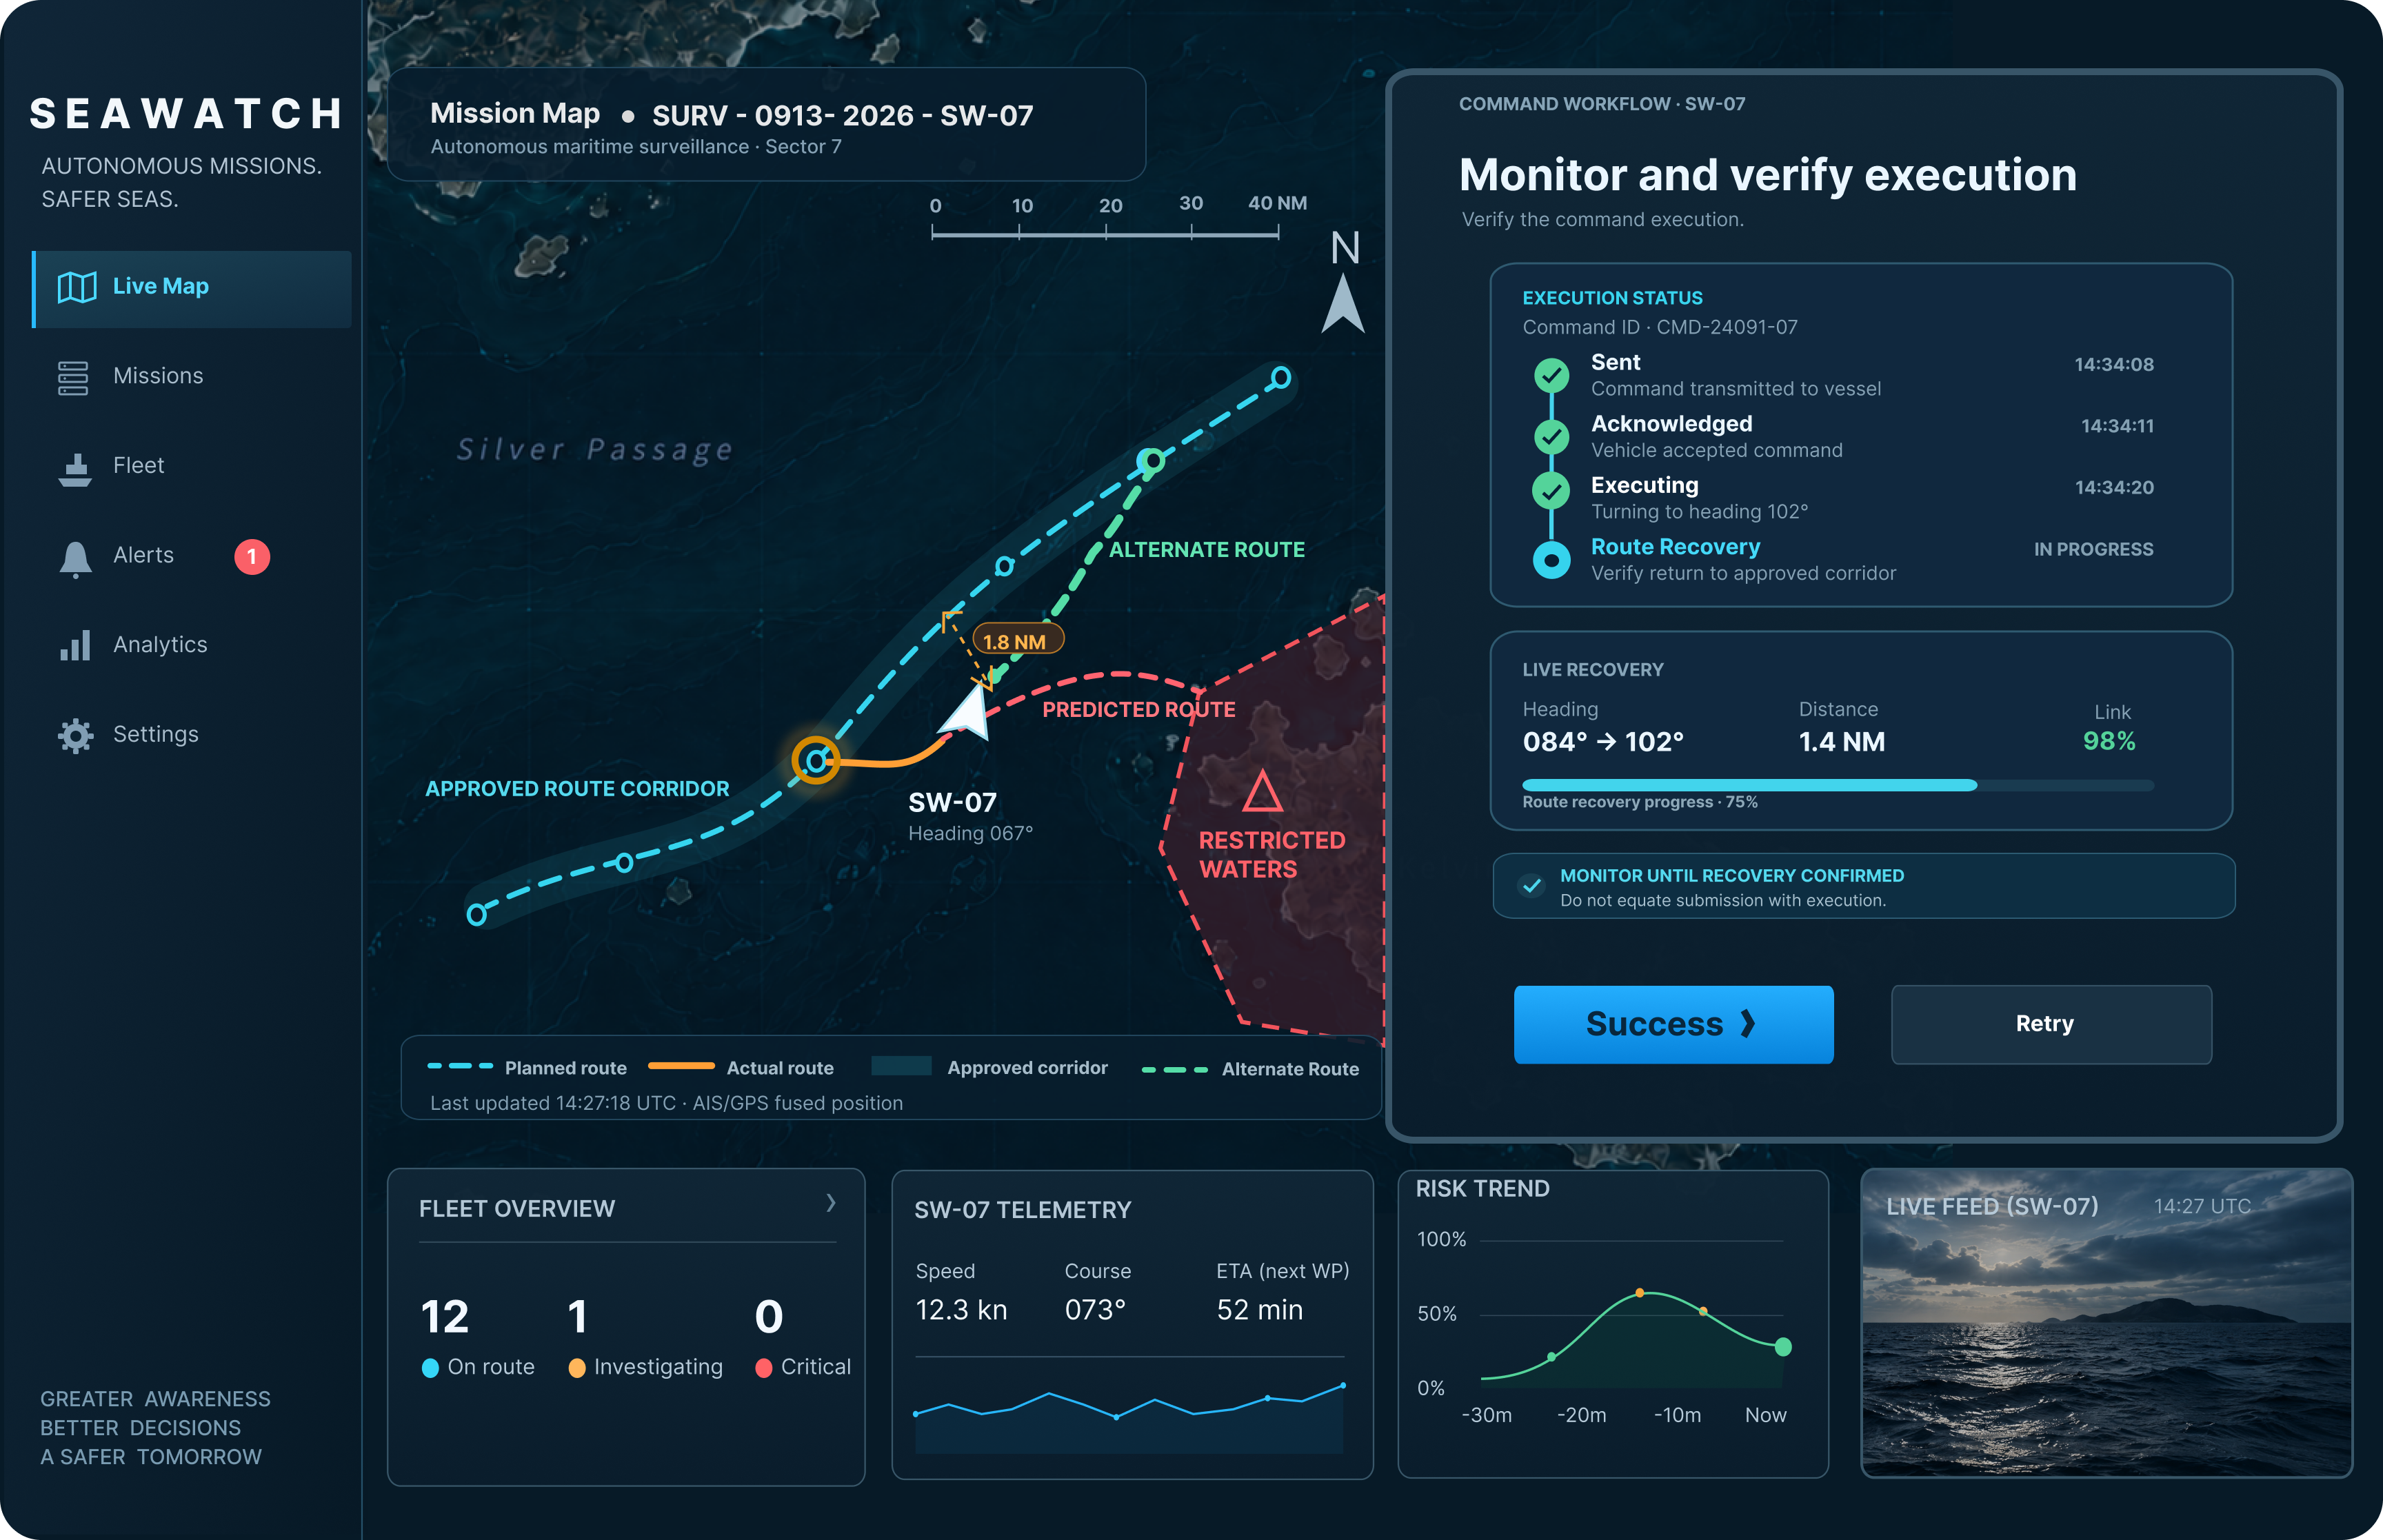

SeaWatch separates command submission from vehicle acknowledgment and execution so the operator always understands the real system state.
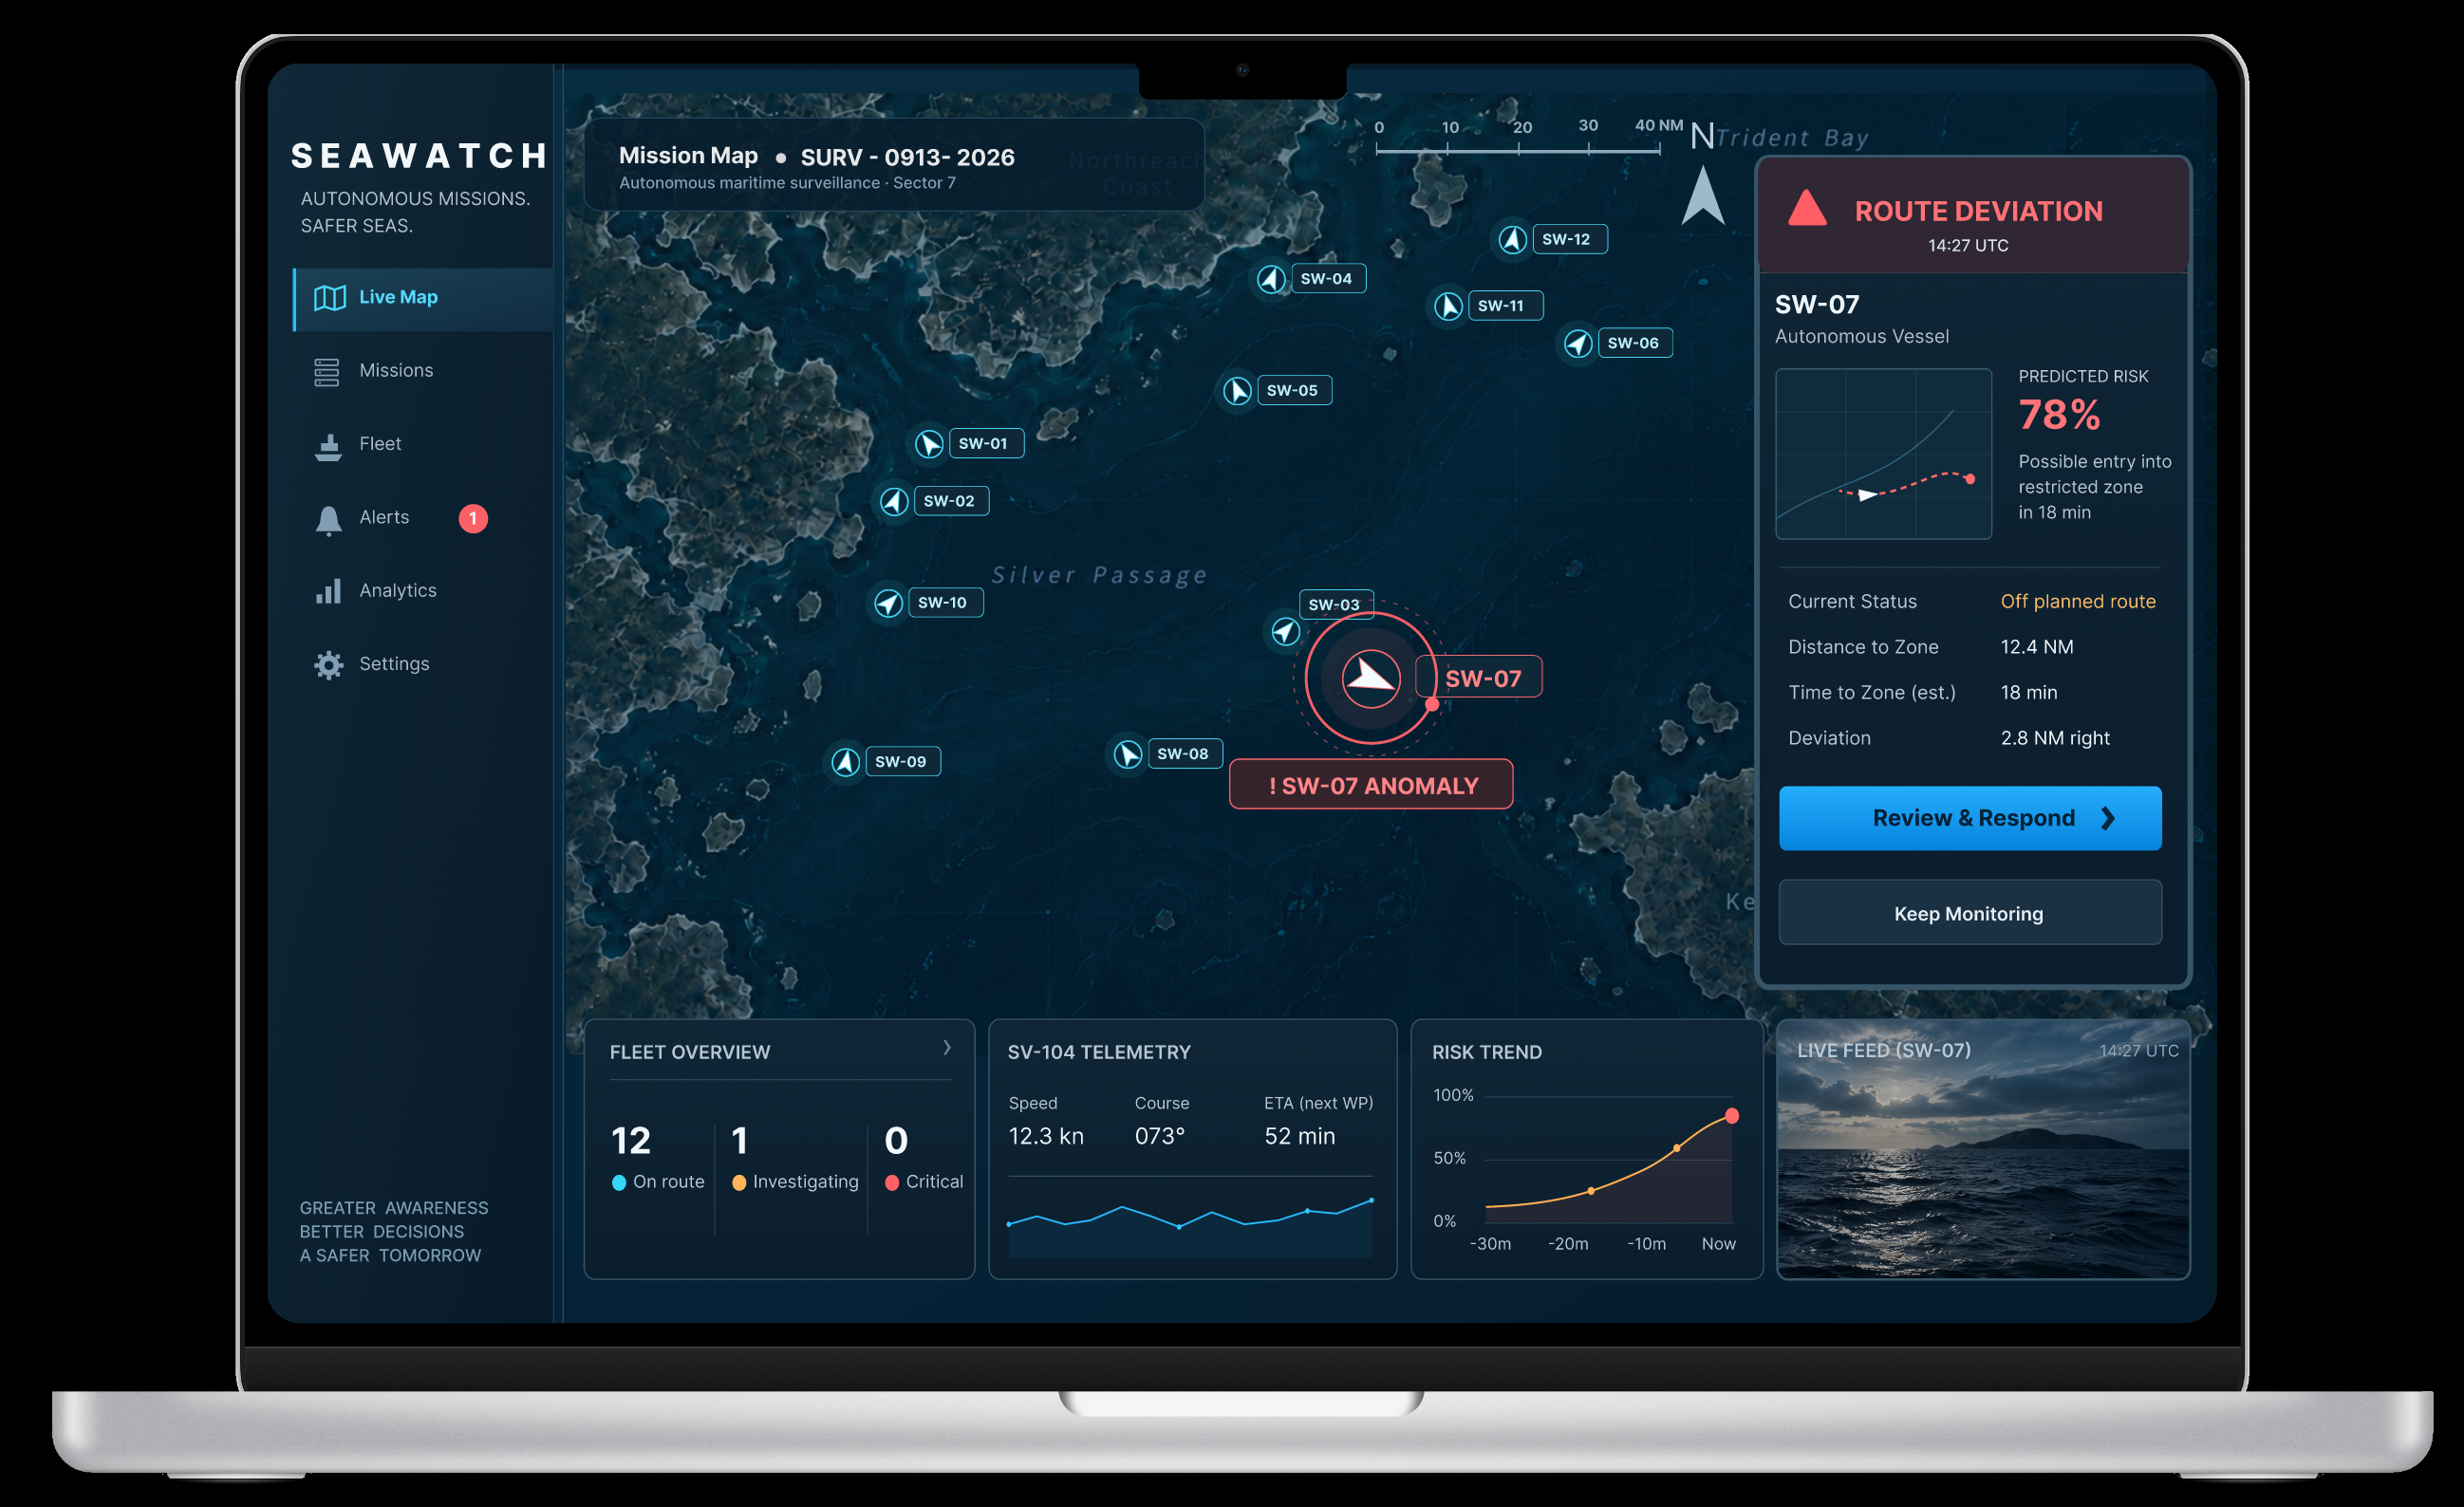
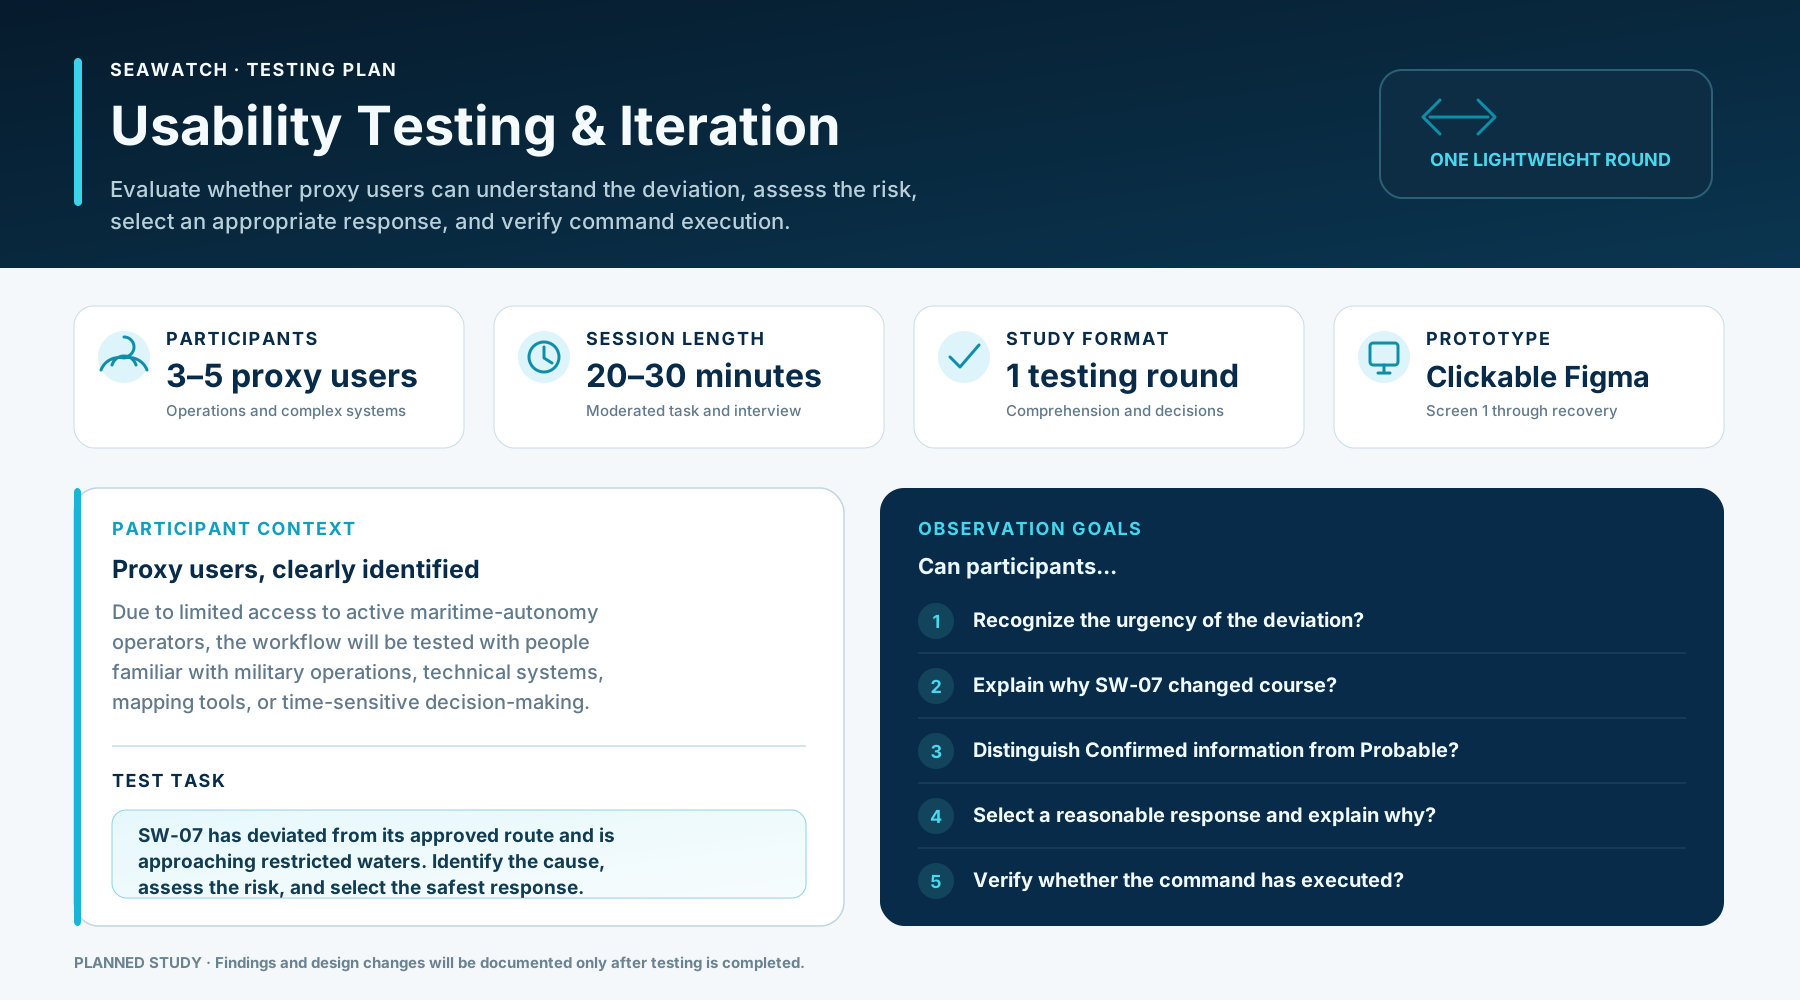
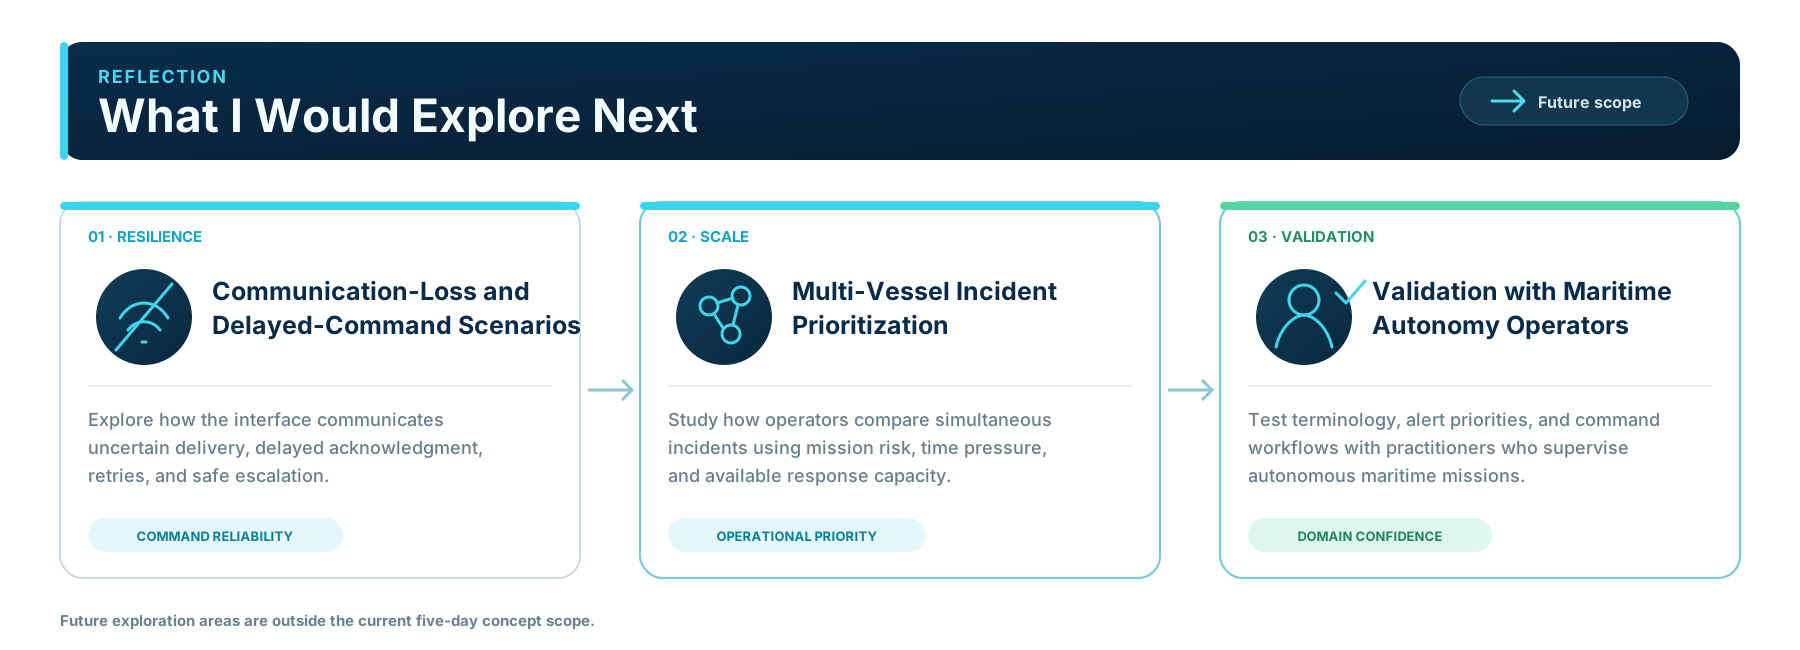
The final prototype transforms route-deviation response from a fragmented monitoring task into a guided decision workflow. Operators can understand the cause, evaluate the risk, compare response options, and verify command execution without losing sight of the broader mission context.
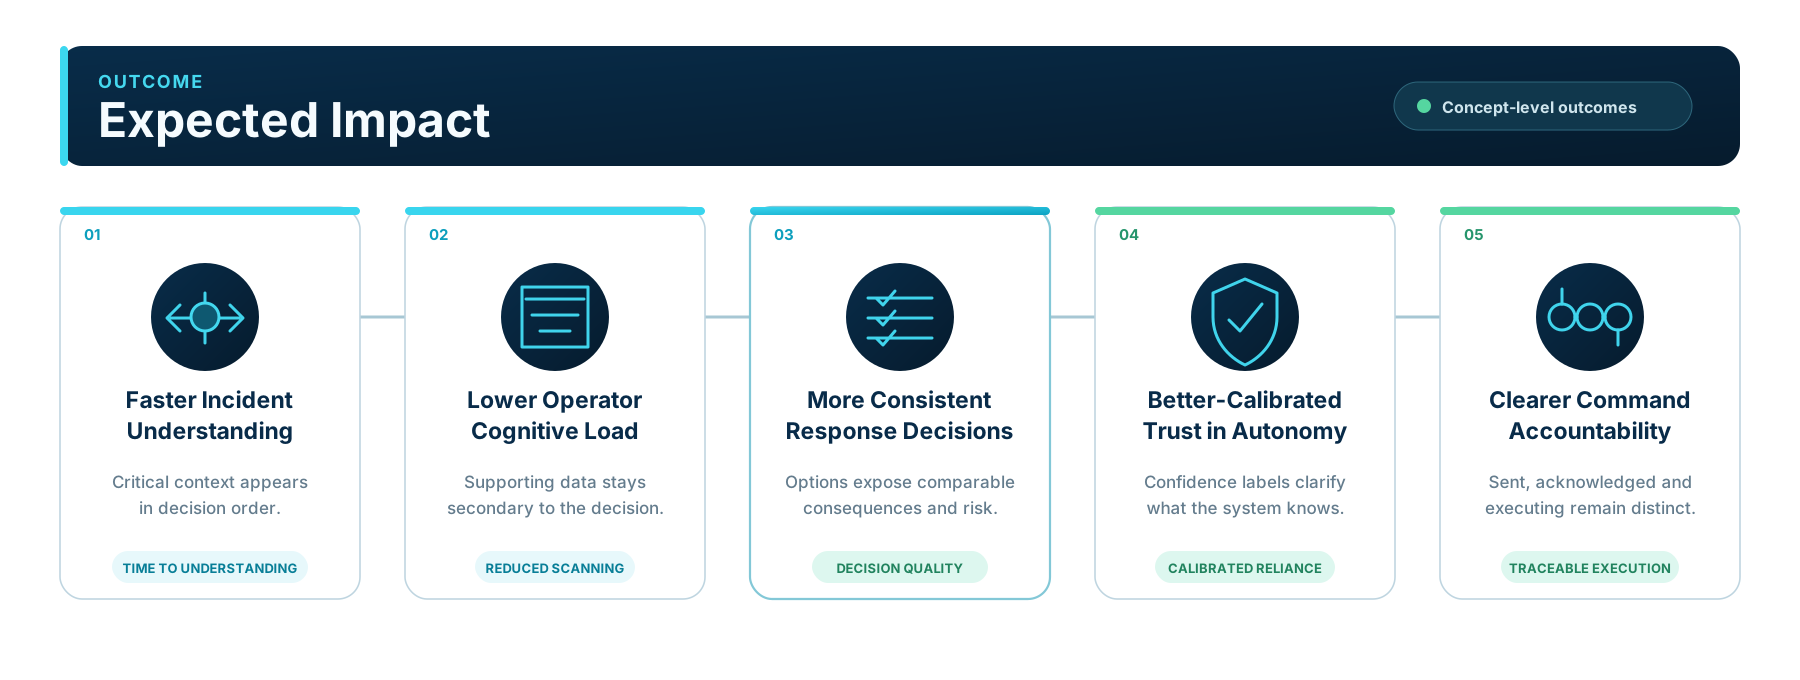
Designing for autonomous systems is not only about giving operators control. It is about helping them understand when to trust autonomy, when to intervene, and what will happen after an intervention.